Description
| Parameter | Unit | Option 1 | Option 2 | Option 3 |
|---|---|---|---|---|
| Winding Type | — | Unipolar / Bipolar | Unipolar / Bipolar | Unipolar / Bipolar |
| Motor Configuration | — | External Linear Actuator | External Linear Actuator | External Linear Actuator |
| Step Angle | ° | 18 | 18 | 18 |
| Operating Voltage | V | 4 | 5 | 12 |
| Current per Phase | mA | 200 | 160 | 70 |
| Resistance per Phase | Ω | 20 | 33 | 180 |
| Inductance per Phase | mH | 506 | 8.7 | 49 |
| Parameter | Unit | Available Options |
|---|---|---|
| Linear Travel per Step | mm | 0.02 / 0.025 / 0.05 |
Note: Parameters can be customized according to customer requirements. Available lead screw diameters: 3.0 mm; available leads: 0.5 mm, 1.0 mm. Step size = (step angle / 360) × lead (mm).
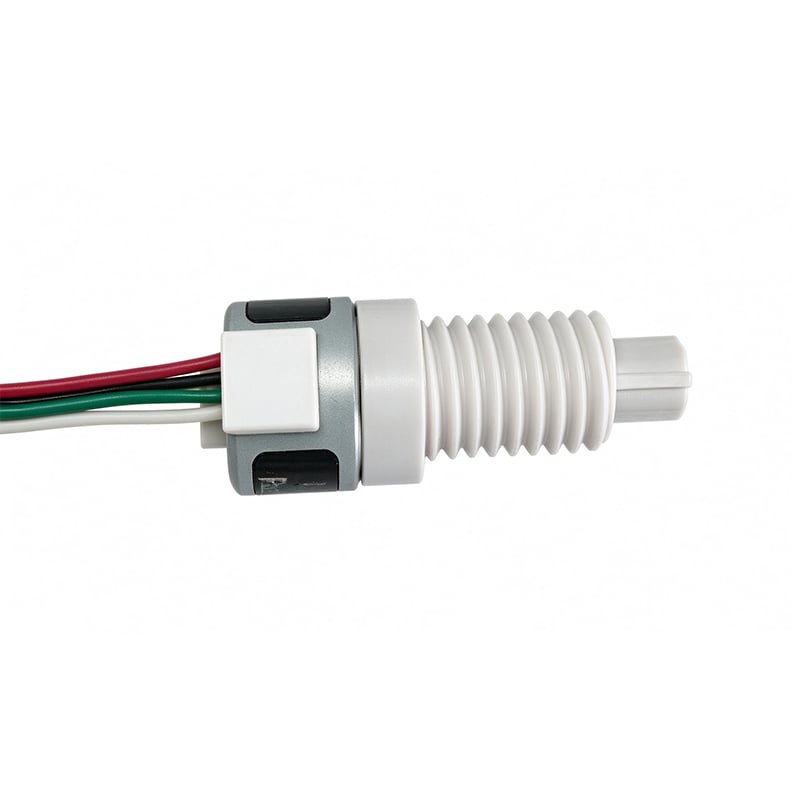
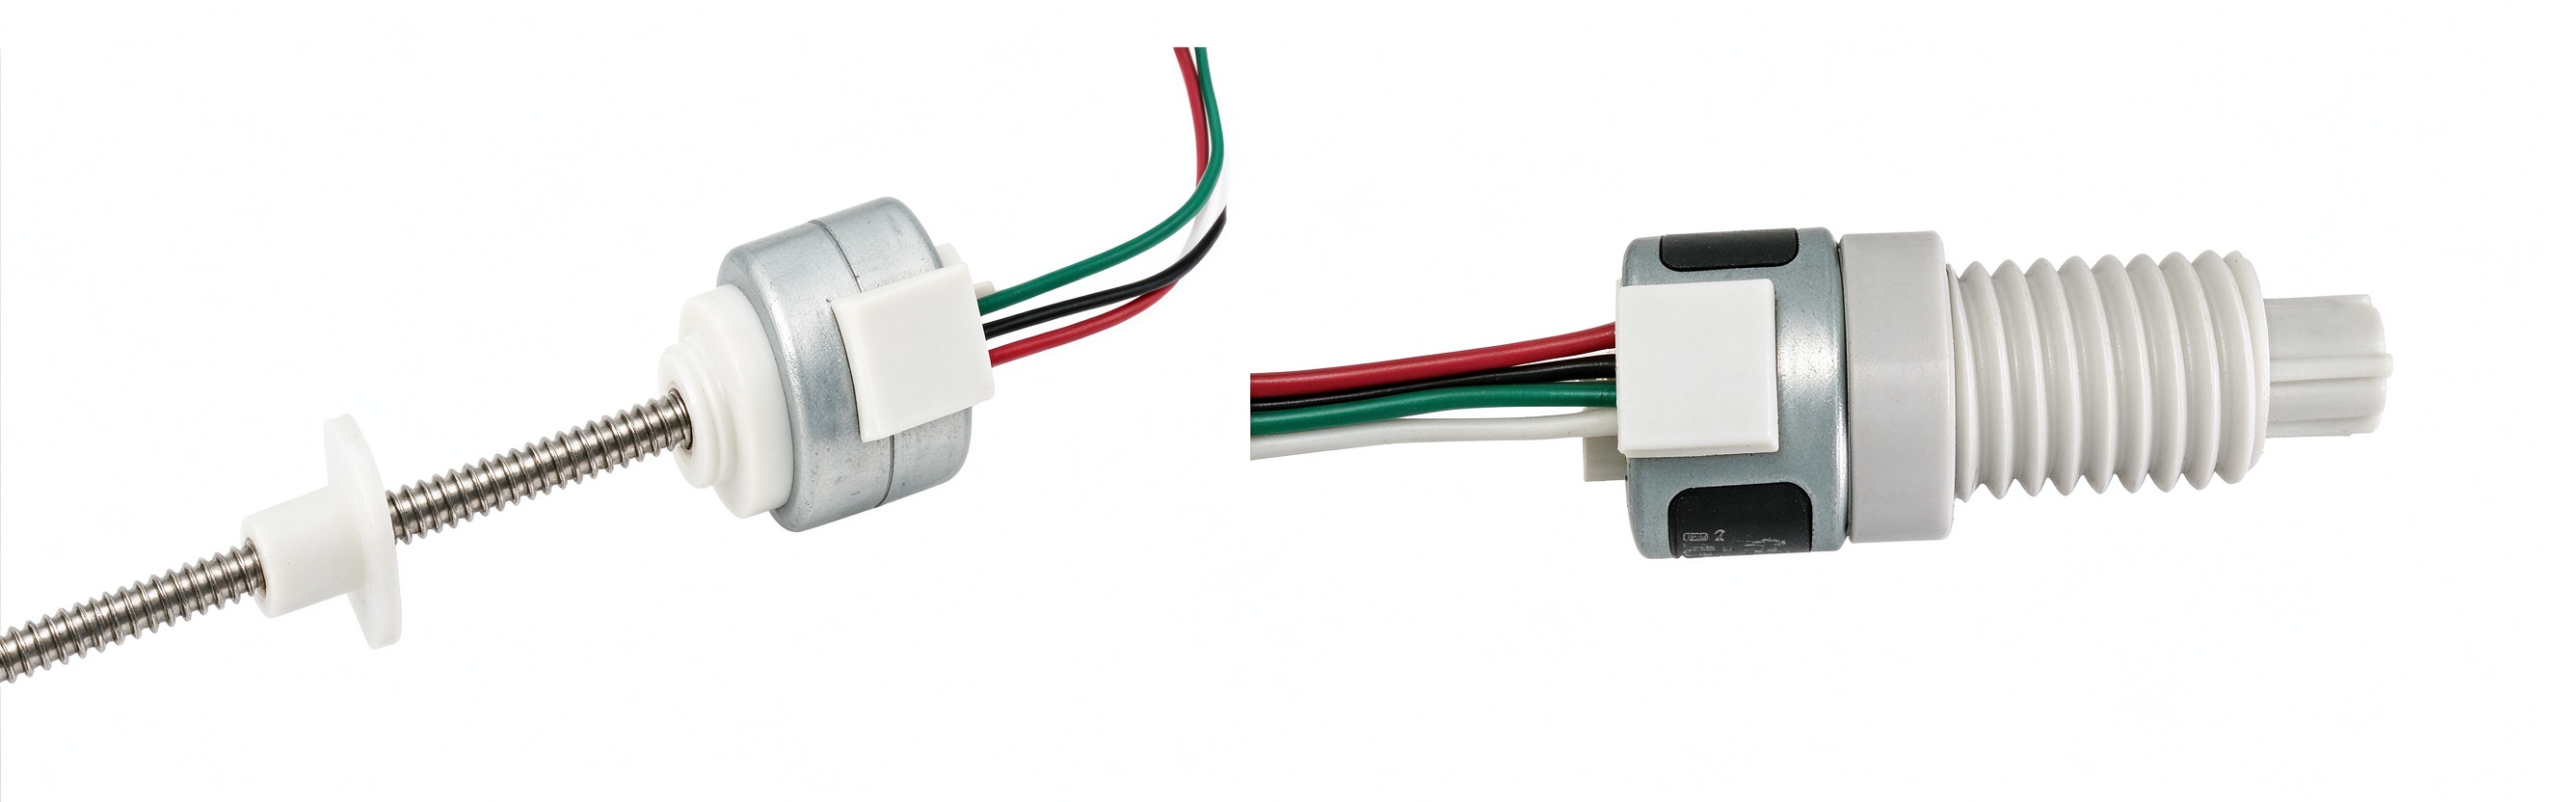
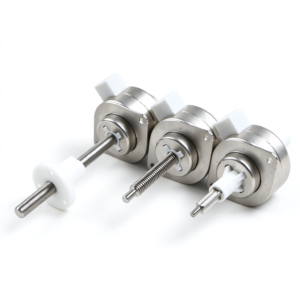
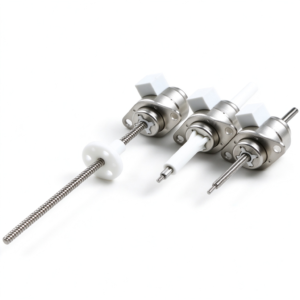
1. Externally driven type
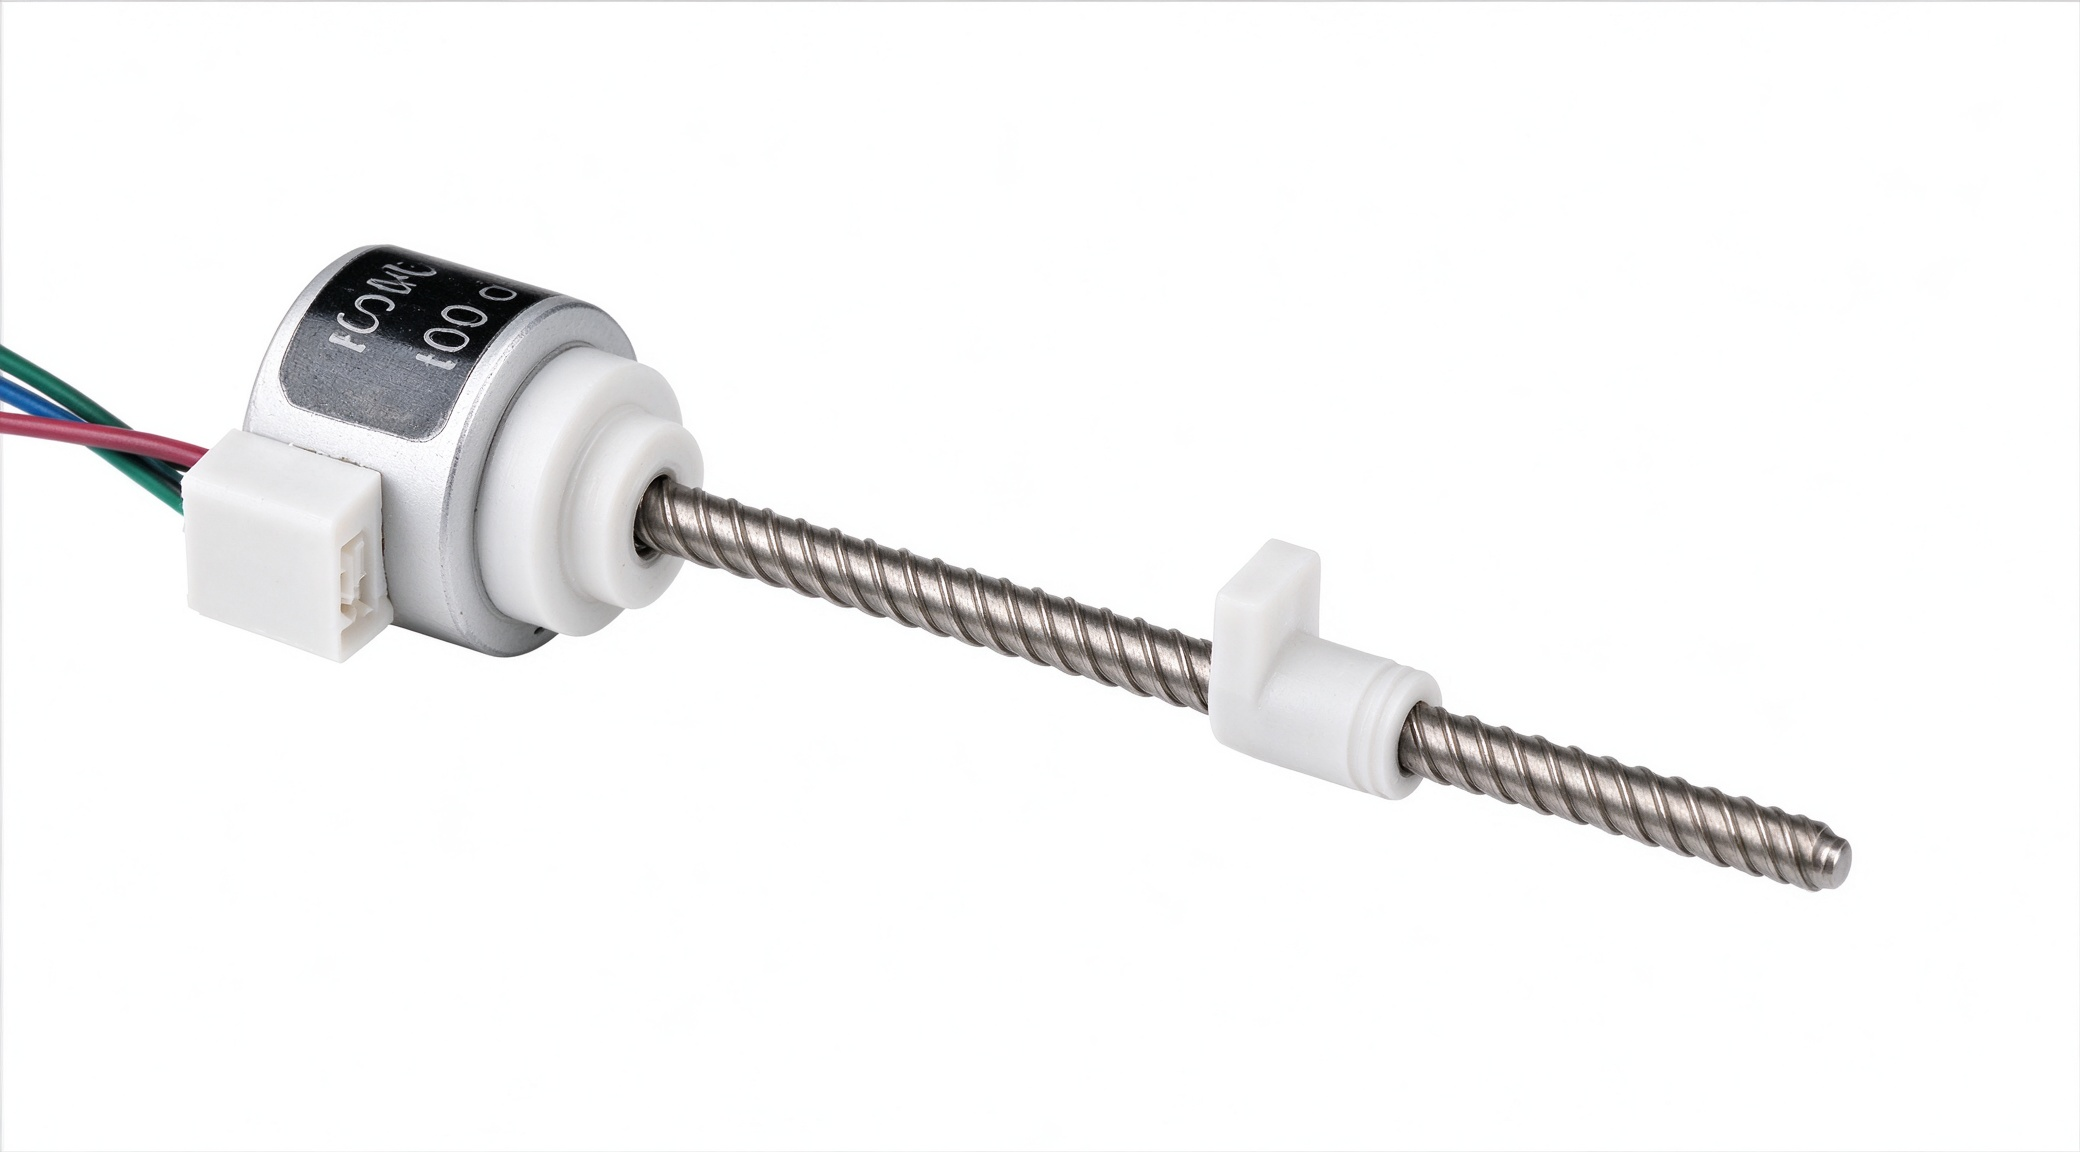
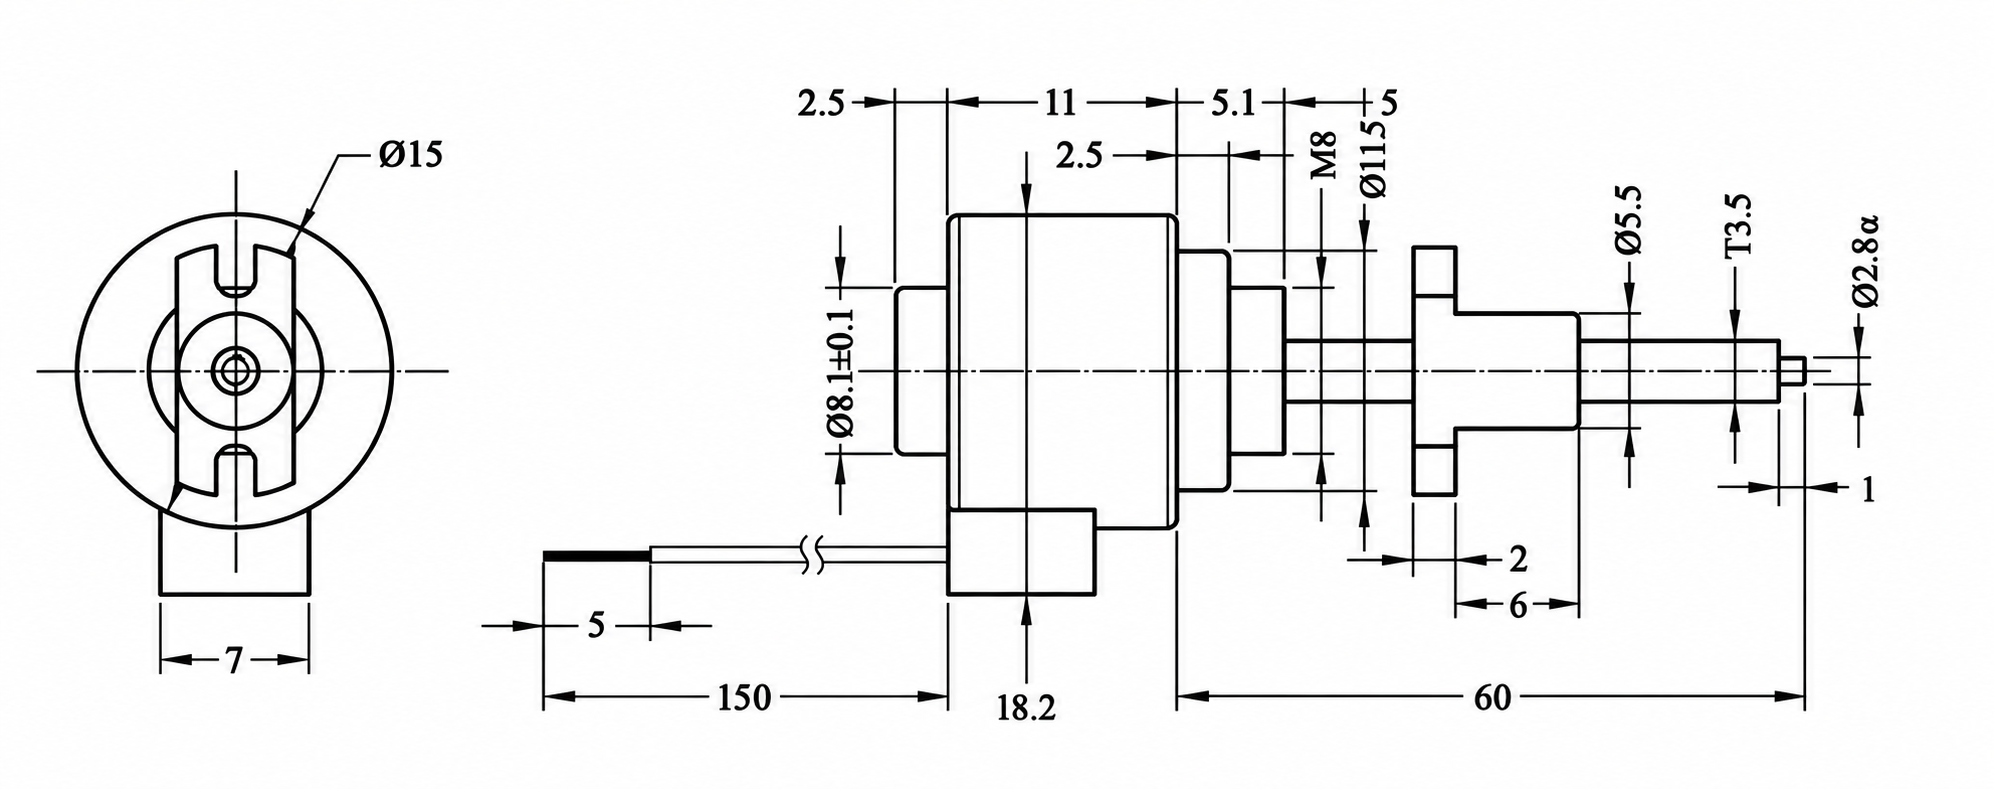
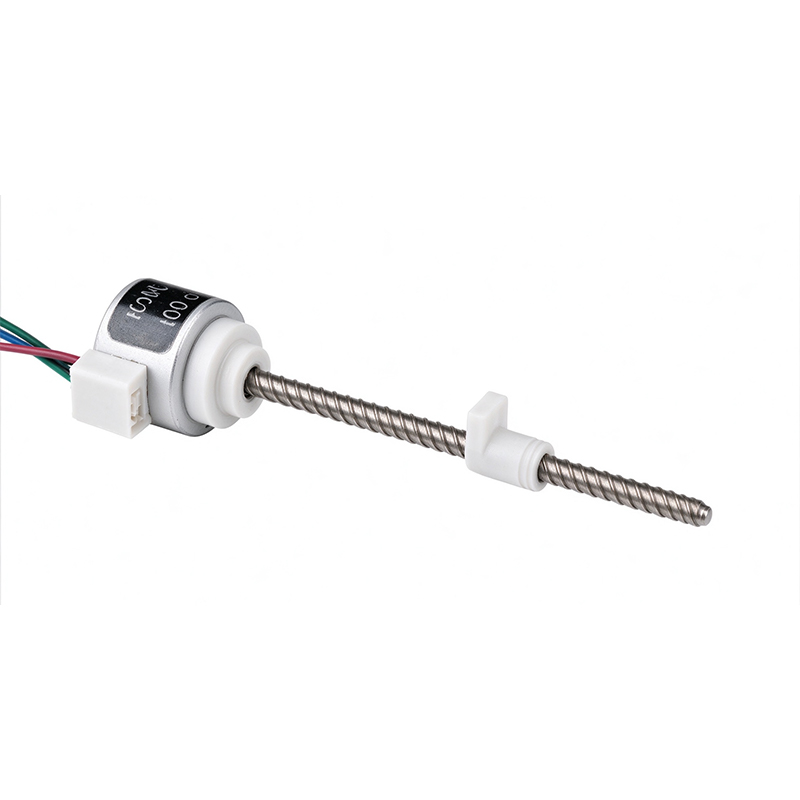
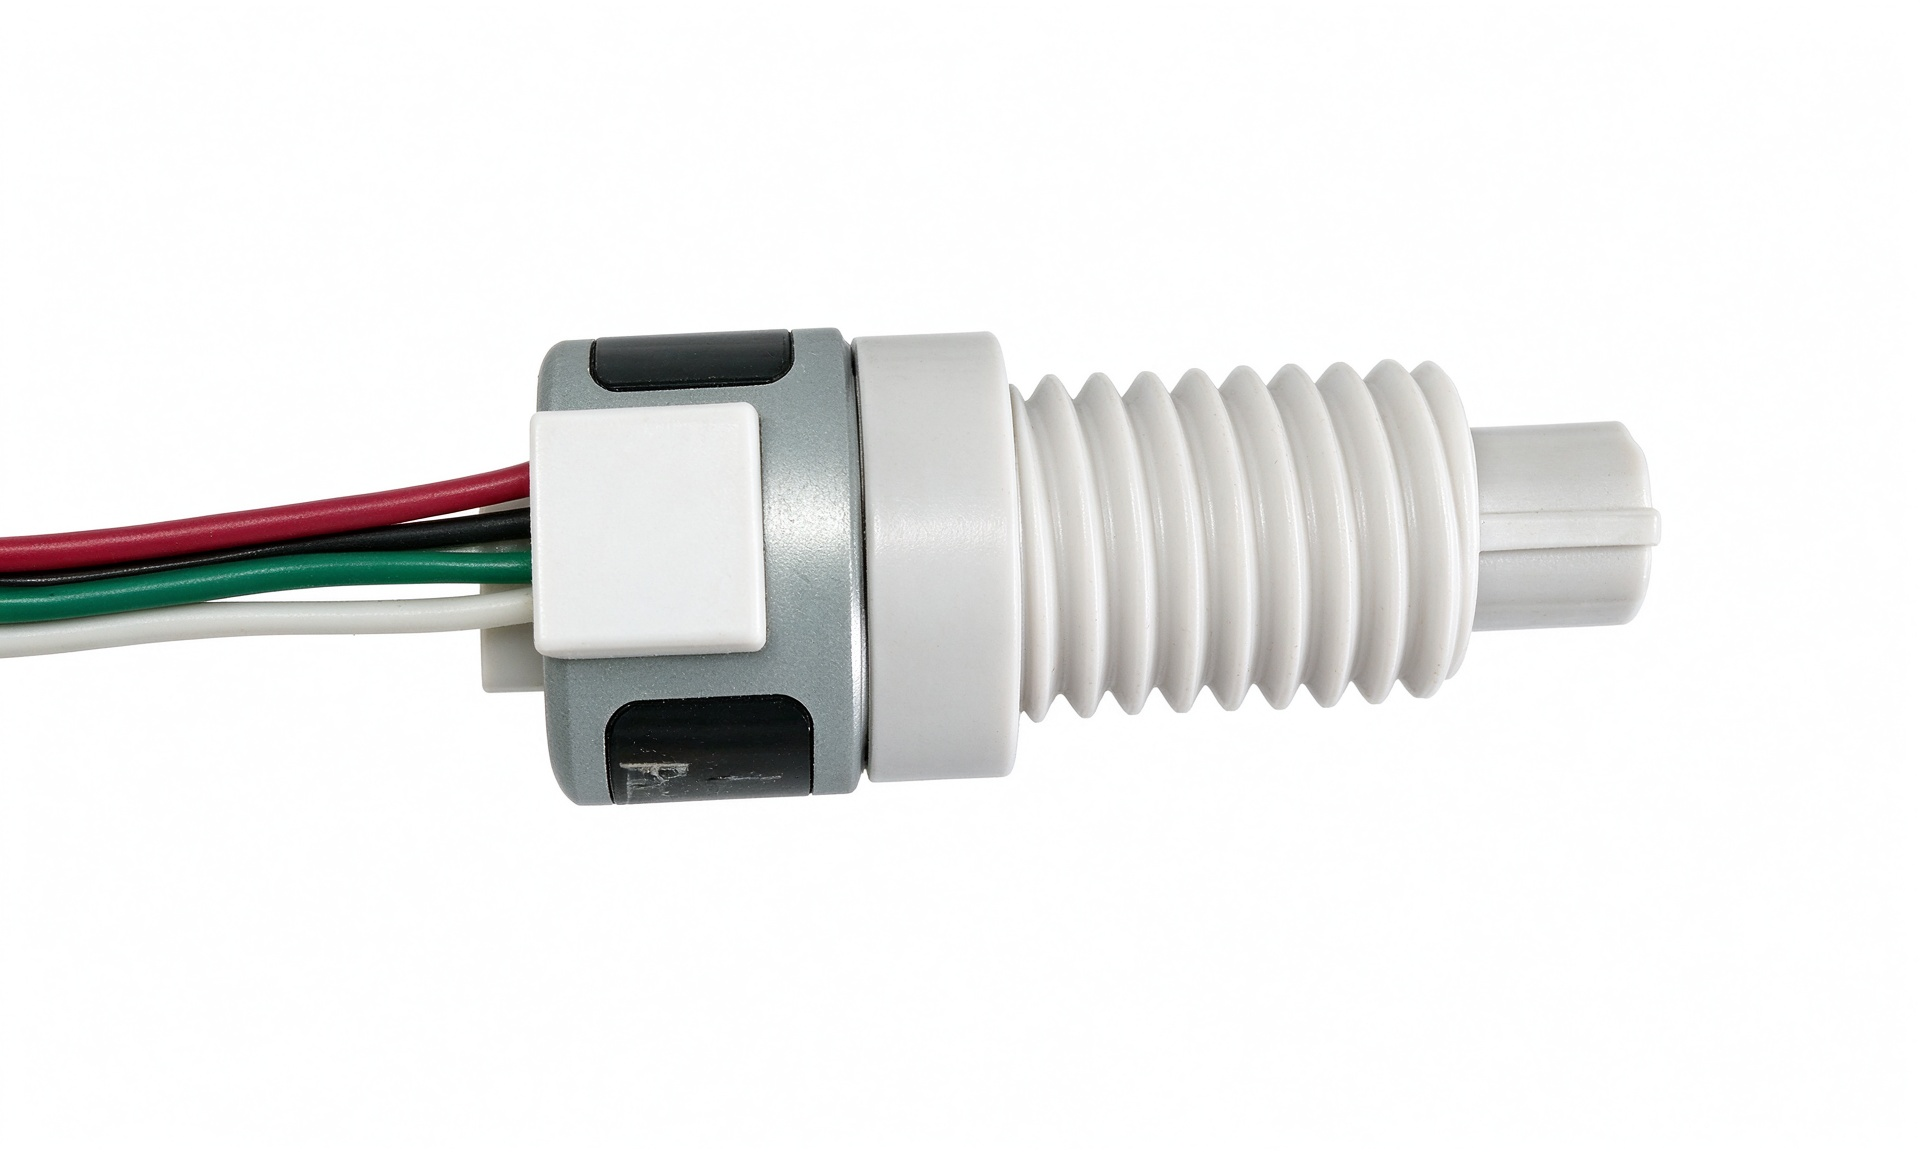
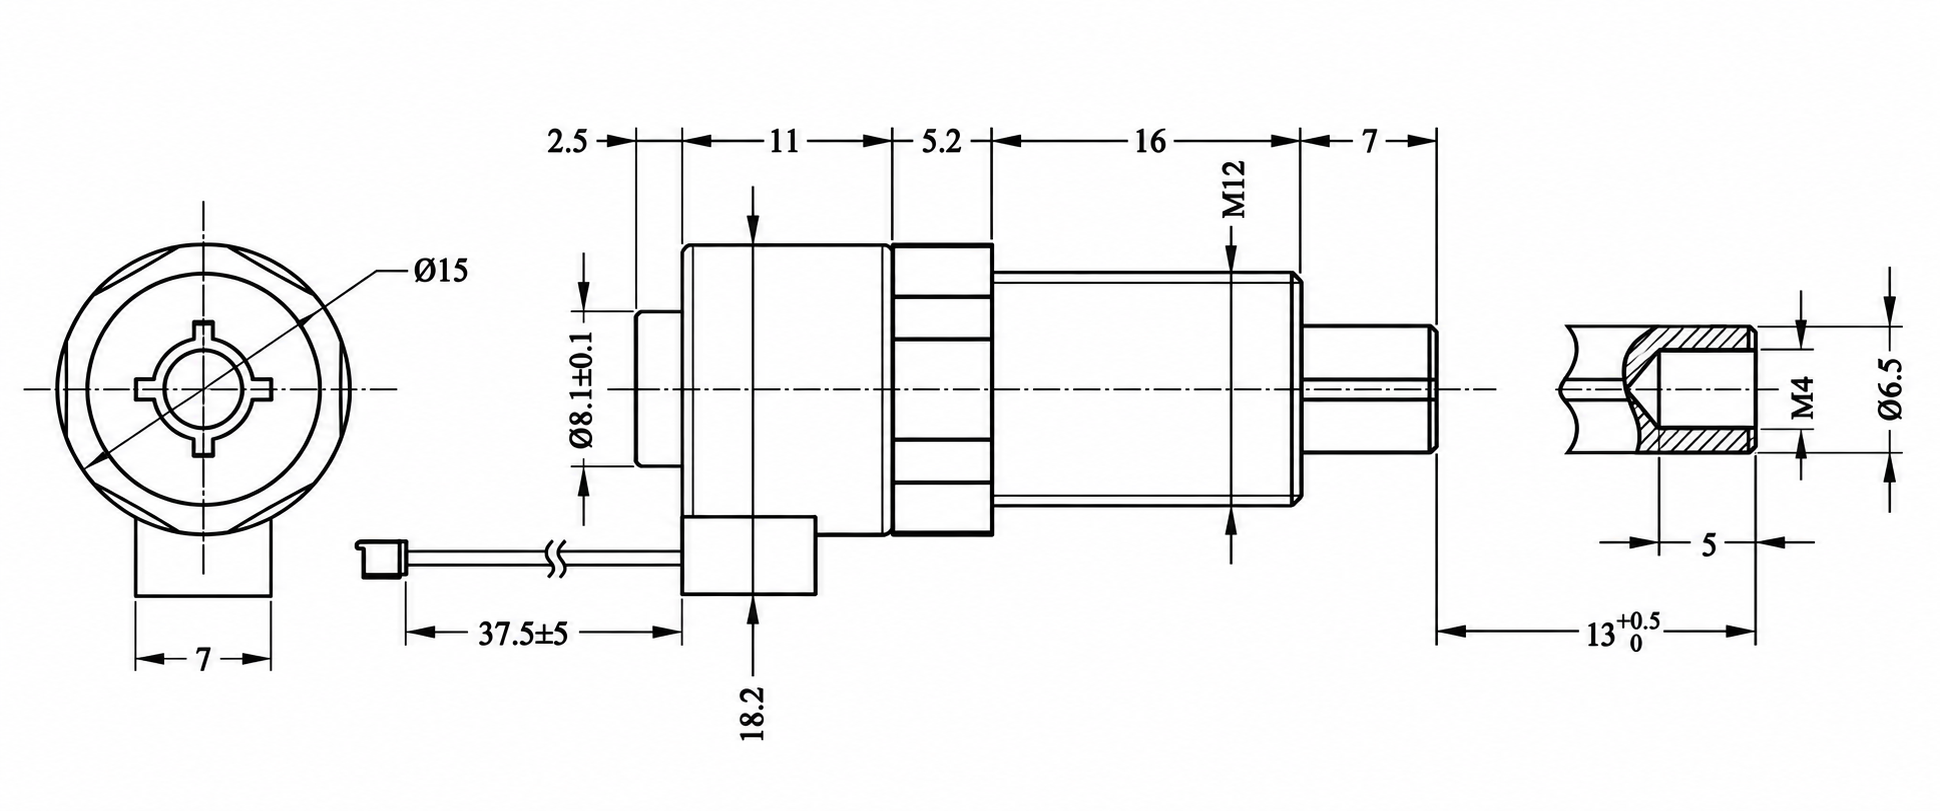
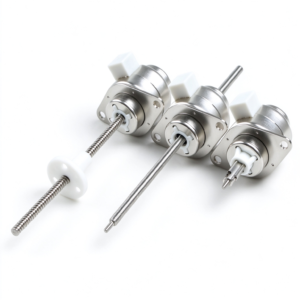
2. Fixed-axis type
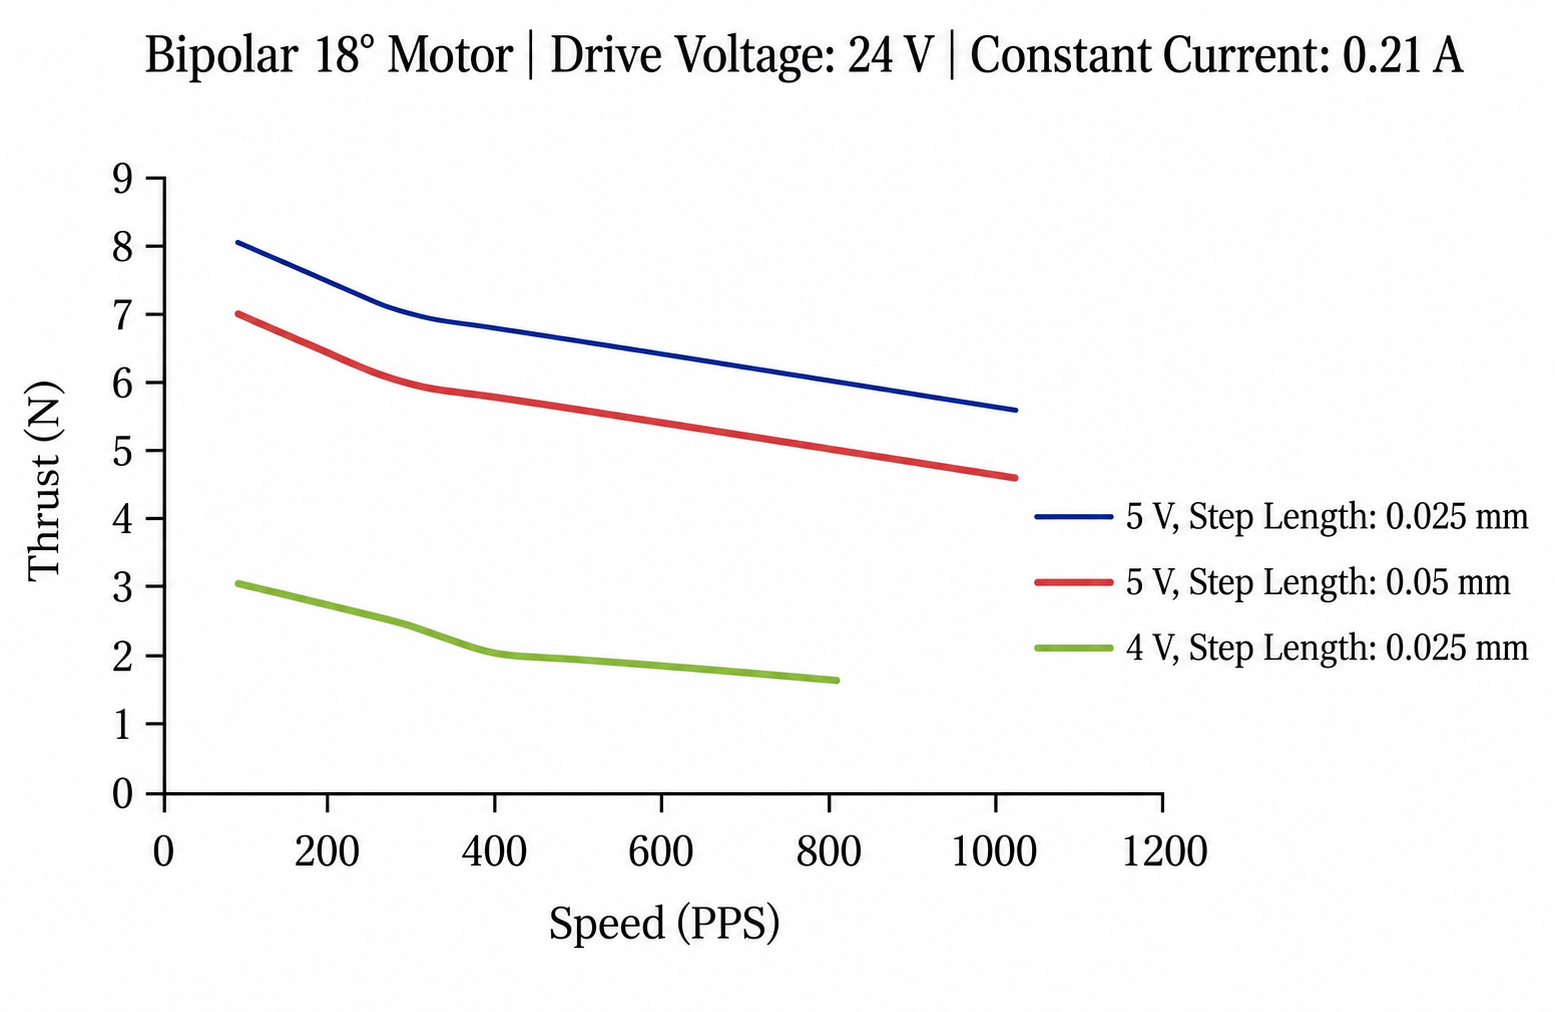
3、Step speed and thrust curve
Product Overview
The Φ15 Series converts sequential winding excitation into stepping motion. A matching screw-and-nut mechanism translates rotary stepping action into linear displacement.
The selected configuration determines which component moves and how the assembly requires support. Depending on the design, the mechanism may need external guidance or an anti-rotation arrangement to produce the intended linear travel.
Linear movement per step depends on the motor step angle and screw lead. Available thrust, travel speed, and positioning performance also depend on the driver, friction, alignment, and applied load.
Key Features
Incremental Linear Movement
Step-based operation allows a compatible controller to command movement in defined increments. This supports mechanisms that require repeated adjustments or movement between operating positions.
Permanent Magnet Stepper Technology
The permanent magnet rotor interacts with magnetic fields generated by the stator windings. Sequential excitation produces the motion that drives the linear transmission.
Forward and Reverse Travel
An appropriate excitation sequence supports advancing and retracting movement. This capability suits adjustment mechanisms that need to move in both directions during an operating cycle.
Integrated Linear Drive Concept
Combining a stepper motor with a matching linear transmission can simplify the arrangement of small actuation assemblies. The complete installation must still provide the guidance and support required by the selected configuration.
Programmable Movement Sequences
A suitable controller can coordinate movement, pauses, and direction changes. Sensors and reference switches can supplement these commands when the equipment requires travel limits or position confirmation.
Potential Applications
Depending on the selected configuration and confirmed operating capabilities, the Φ15 Series may suit:
- Instrument Adjustment: Linear movement of guides, stops, or adjustable components.
- Optical Mechanisms: Positioning compatible focusing or alignment assemblies.
- Small Actuators: Advancing and retracting components within a guided mechanism.
- Automation Devices: Performing repeated linear adjustments under electronic control.
- Appliance Mechanisms: Moving internal components during programmed equipment cycles.
Linear Guidance and Load Support
A suitable guide keeps the moving component aligned with the intended travel axis. Where necessary, an anti-rotation feature prevents unwanted rotation of the screw or nut.
Avoid applying side loads or bending forces to the linear drive components. External guidance should carry loads that the motor and screw assembly cannot support.
Check the available stroke and maintain adequate clearance throughout the full movement range. Travel limits should prevent the mechanism from driving beyond its permitted range.
Positioning and Motion Control
The controller determines the requested displacement through step commands. Actual positioning performance depends on screw lead accuracy, backlash, mechanical rigidity, and whether the motor completes each commanded step.
For applications requiring a known starting position, a reference switch can establish a repeatable datum. Additional feedback may be appropriate where the equipment must verify actual movement.
Acceleration and deceleration should suit the moving mass and load resistance. Gradual transitions can help reduce missed steps and mechanical shock.
Driver and Electrical Integration
Select a driver that matches the chosen motor’s winding arrangement and electrical requirements. Verify the connection diagram and excitation sequence before operation.
Assess temperature rise during the complete duty cycle, including periods of energized standstill. Holding a position under power can generate heat even when the mechanism does not move.
Protect wiring from repeated bending, pulling, and contact with moving components. Cable routing should accommodate the full travel of the assembly.
Installation and Selection
Check the mounting arrangement, screw geometry, moving component interface, and surrounding clearance against the product drawing. Maintain alignment between the motor, transmission, and linear guide during assembly.
Evaluate required thrust, travel speed, stroke, duty cycle, and positioning needs together. Testing the selected Φ15 Series motor within the intended mechanism helps assess movement consistency, load capability, and thermal performance.
Reviews
There are no reviews yet.