Description
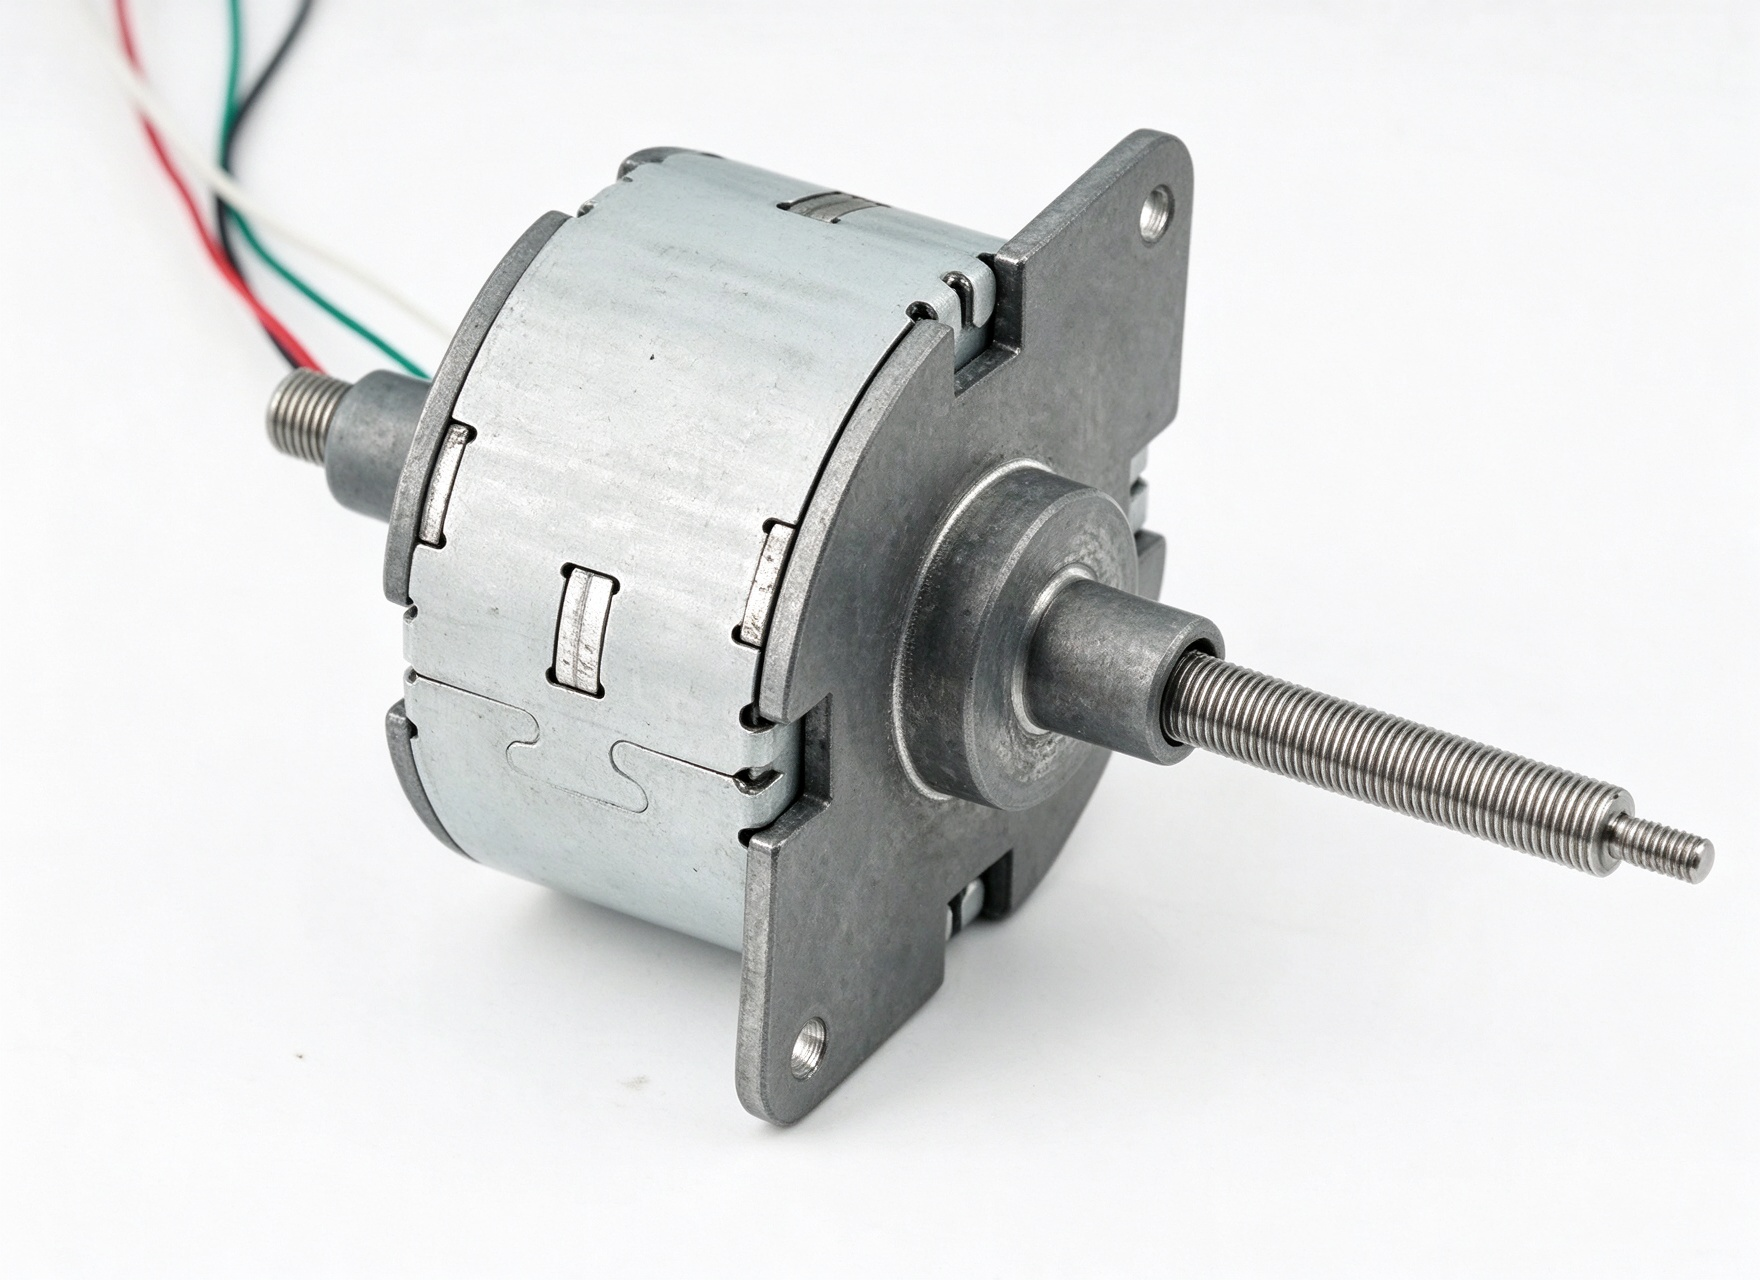
General Specifications
| Parameter | Unit | Specification |
|---|---|---|
| Frame Size | mm | 46 |
| Winding Type | — | Unipolar / Bipolar |
| Motor Configuration | — | Non-Captive / External Linear Actuator |
| Step Angle | ° | 7.5 |
Electrical Specifications
| Parameter | Unit | Option 1 | Option 2 |
|---|---|---|---|
| Operating Voltage | V | 5 | 12 |
| Current per Phase | mA | 1000 | 410 |
| Resistance per Phase | Ω | 5 | 29 |
| Inductance per Phase | mH | 9 | 52 |
Linear Travel per Step
| Travel Option | Unit | Specification |
|---|---|---|
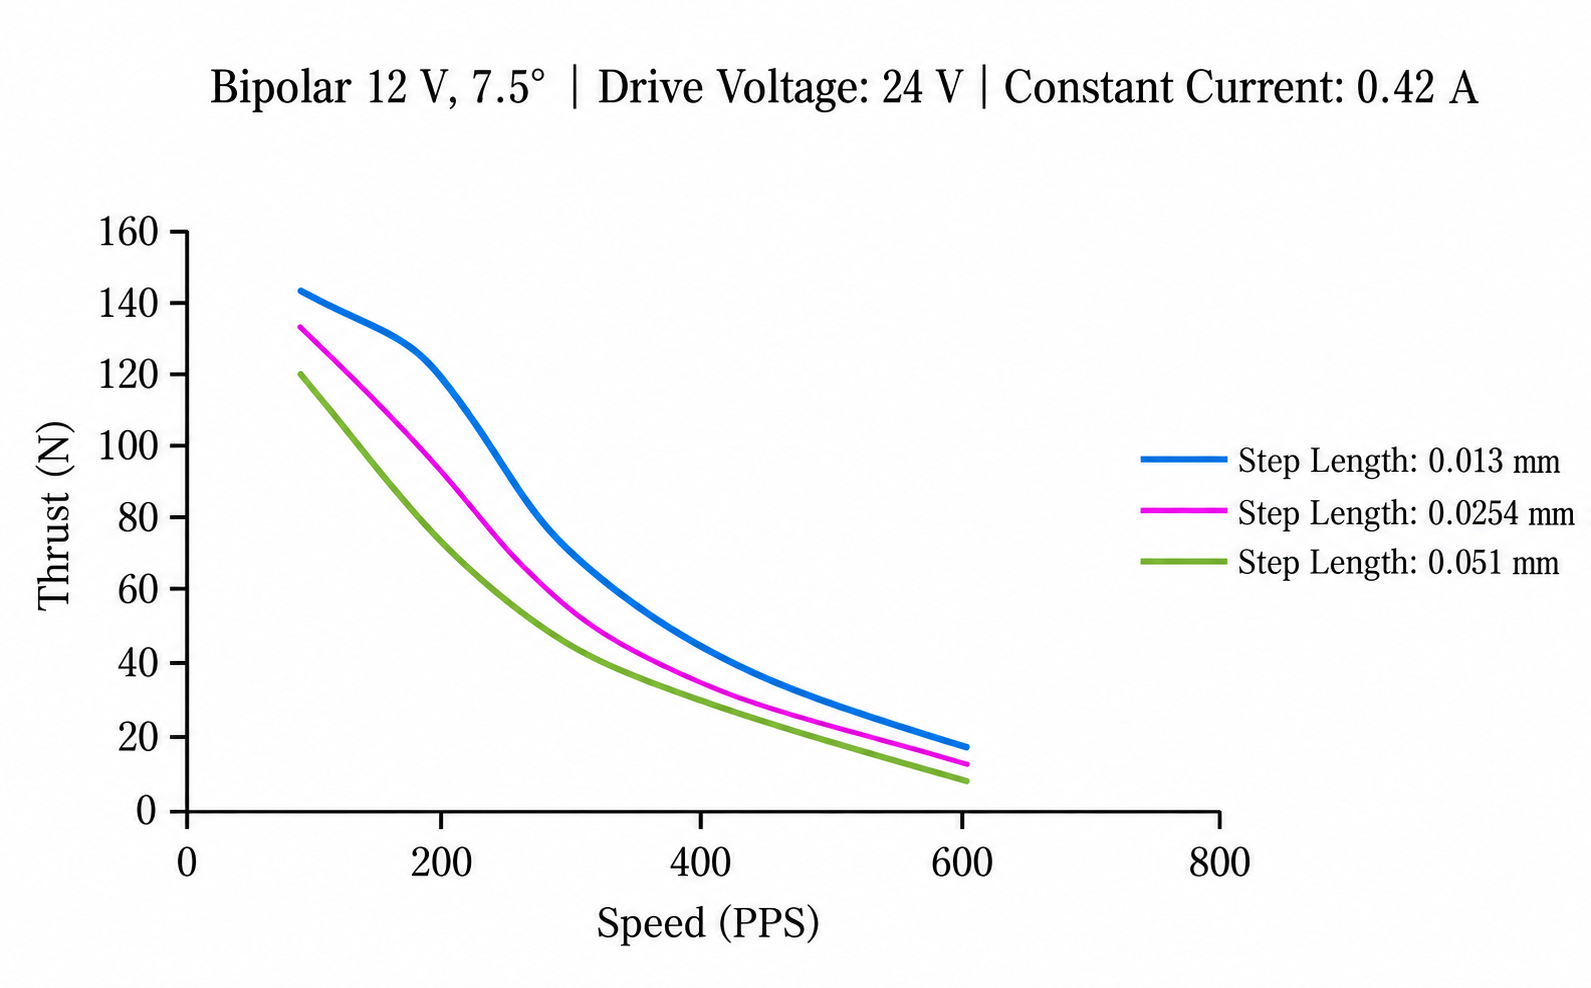
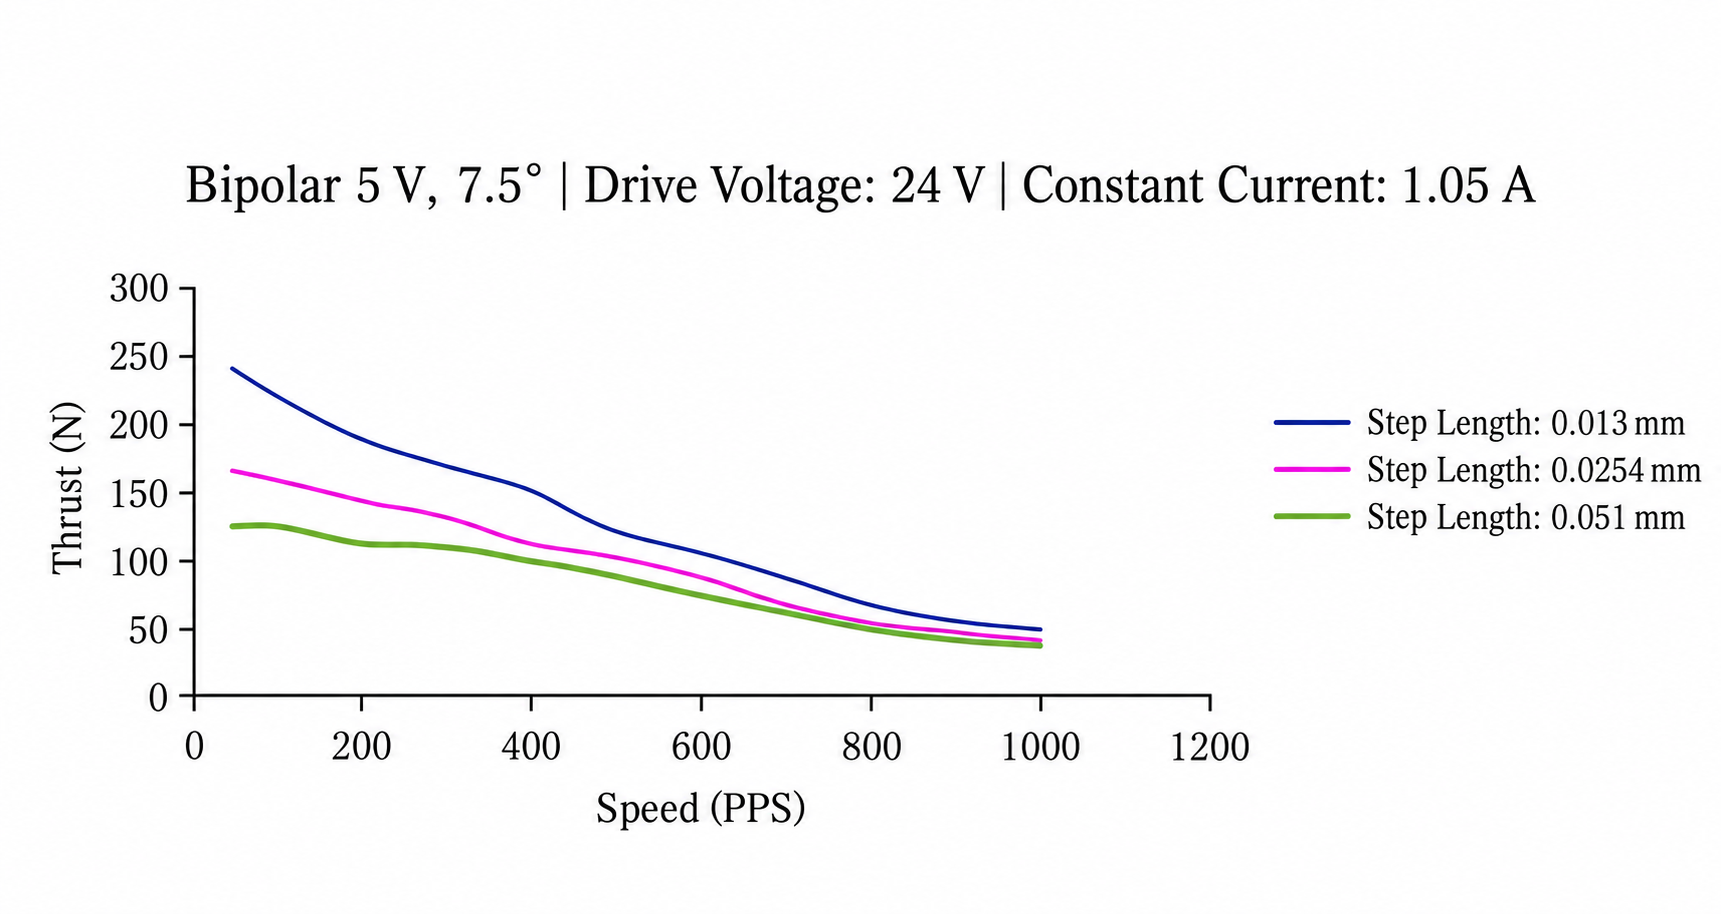
| Option A | mm/step | 0.0127 |
| Option B | mm/step | 0.0254 |
| Option C | mm/step | 0.0508 |
Note: Parameters can be customized according to customer requirements. Available lead screw diameters: ① 6.35 mm, ② 4.77 mm. Available leads: ① 0.6096, 1.0, 1.2192, 1.27, 2.4384, 2.54, 4.0, 8.0… (mm); ② 0.635, 1.27, 2.54, 5.08, 10.16… (mm). Step size = (step angle / 360) × lead (mm).
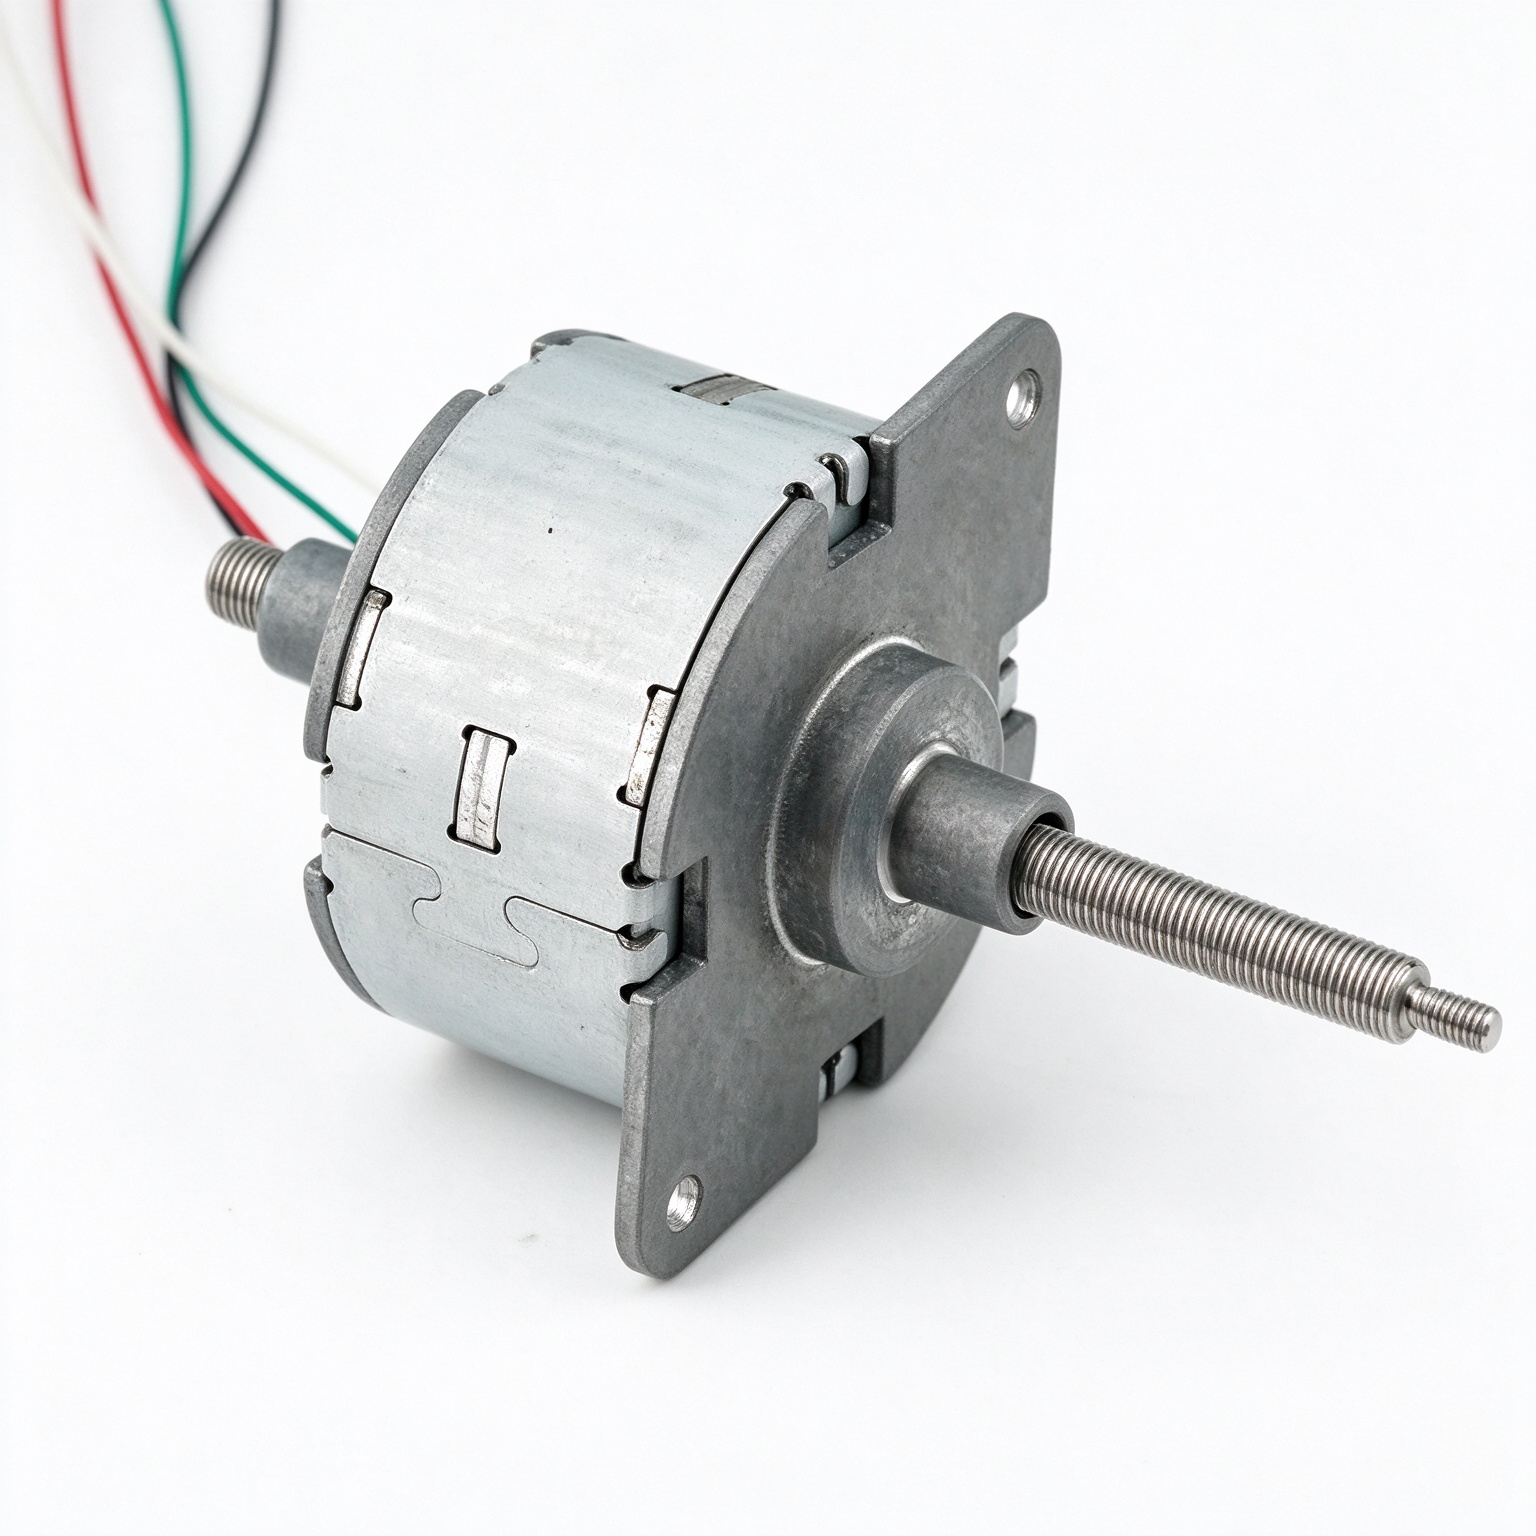
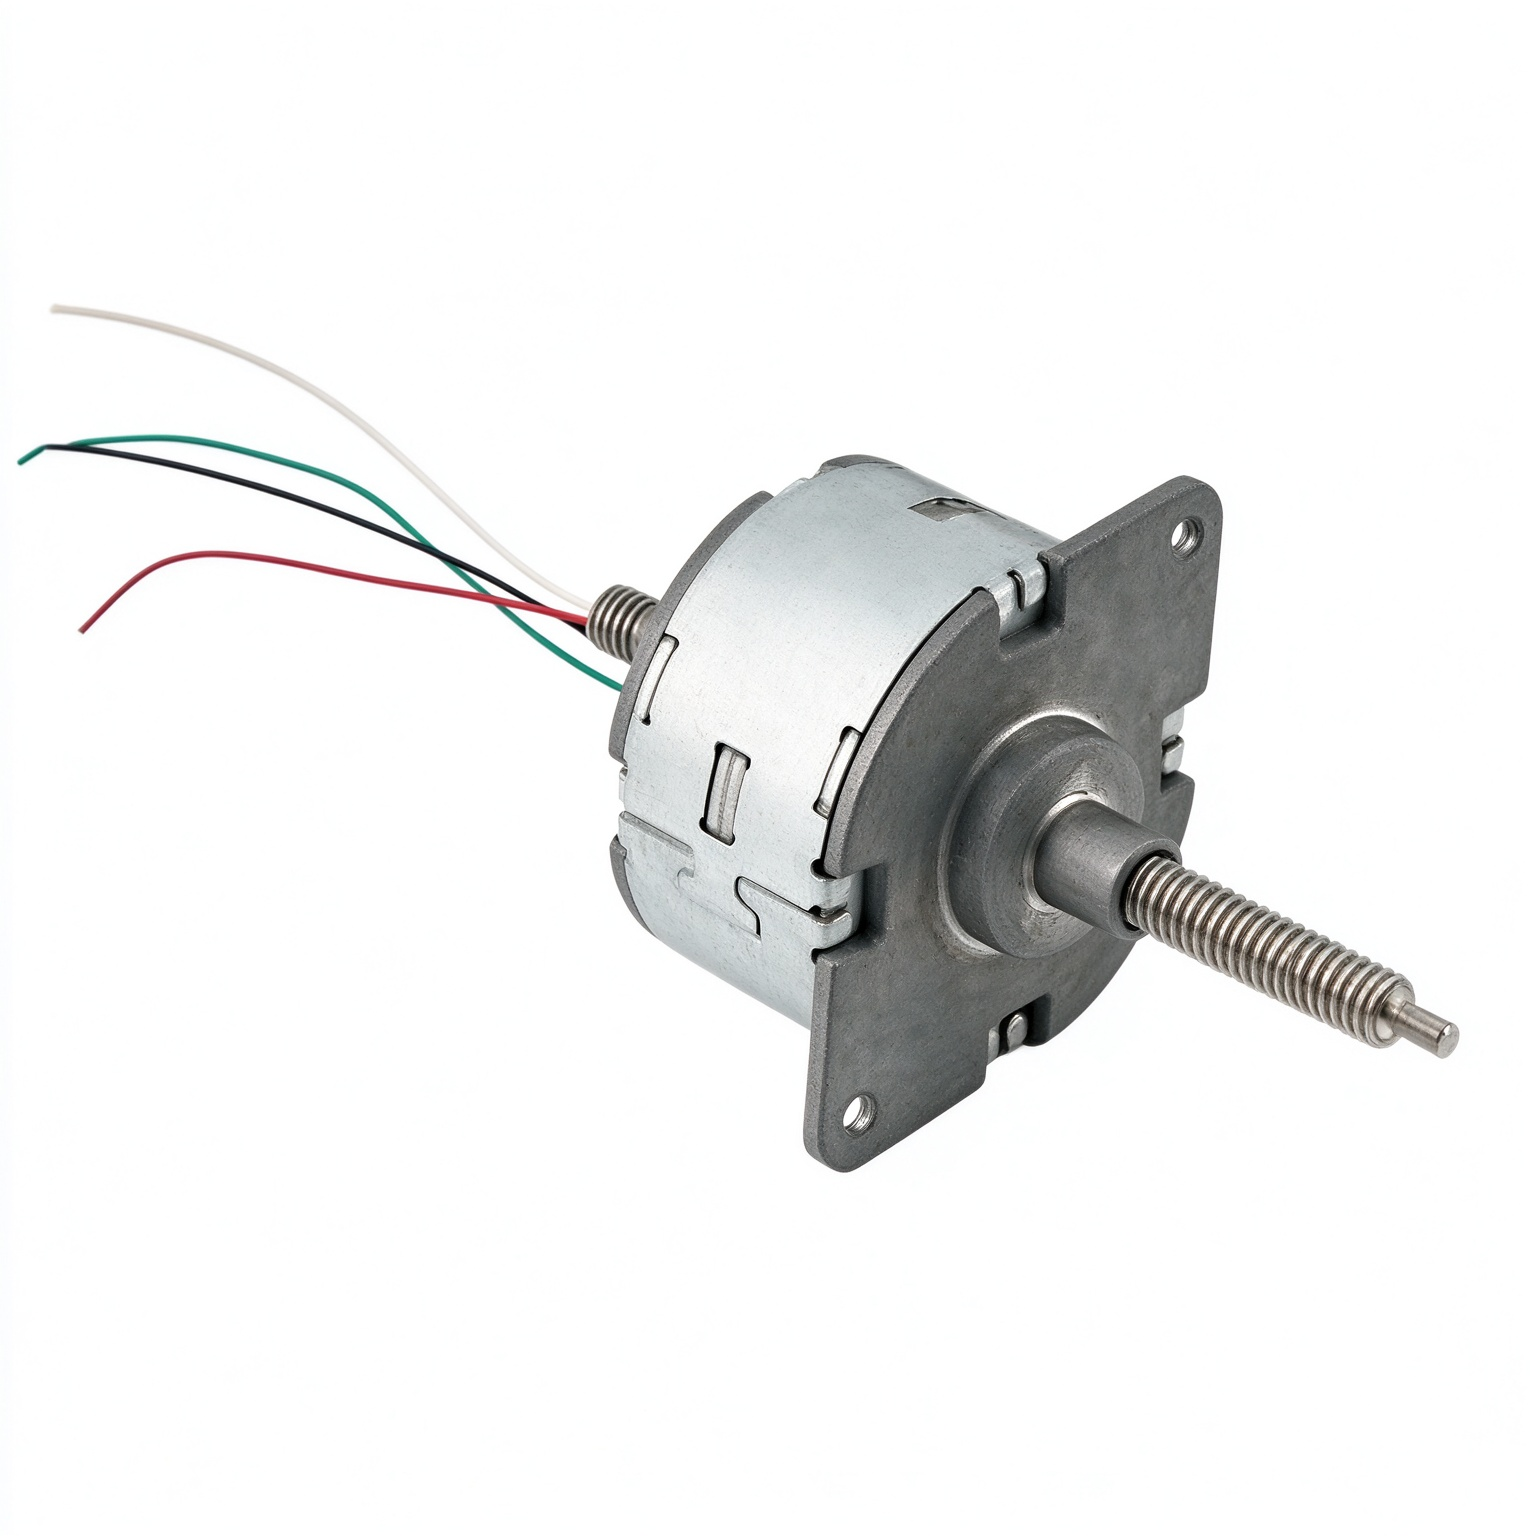
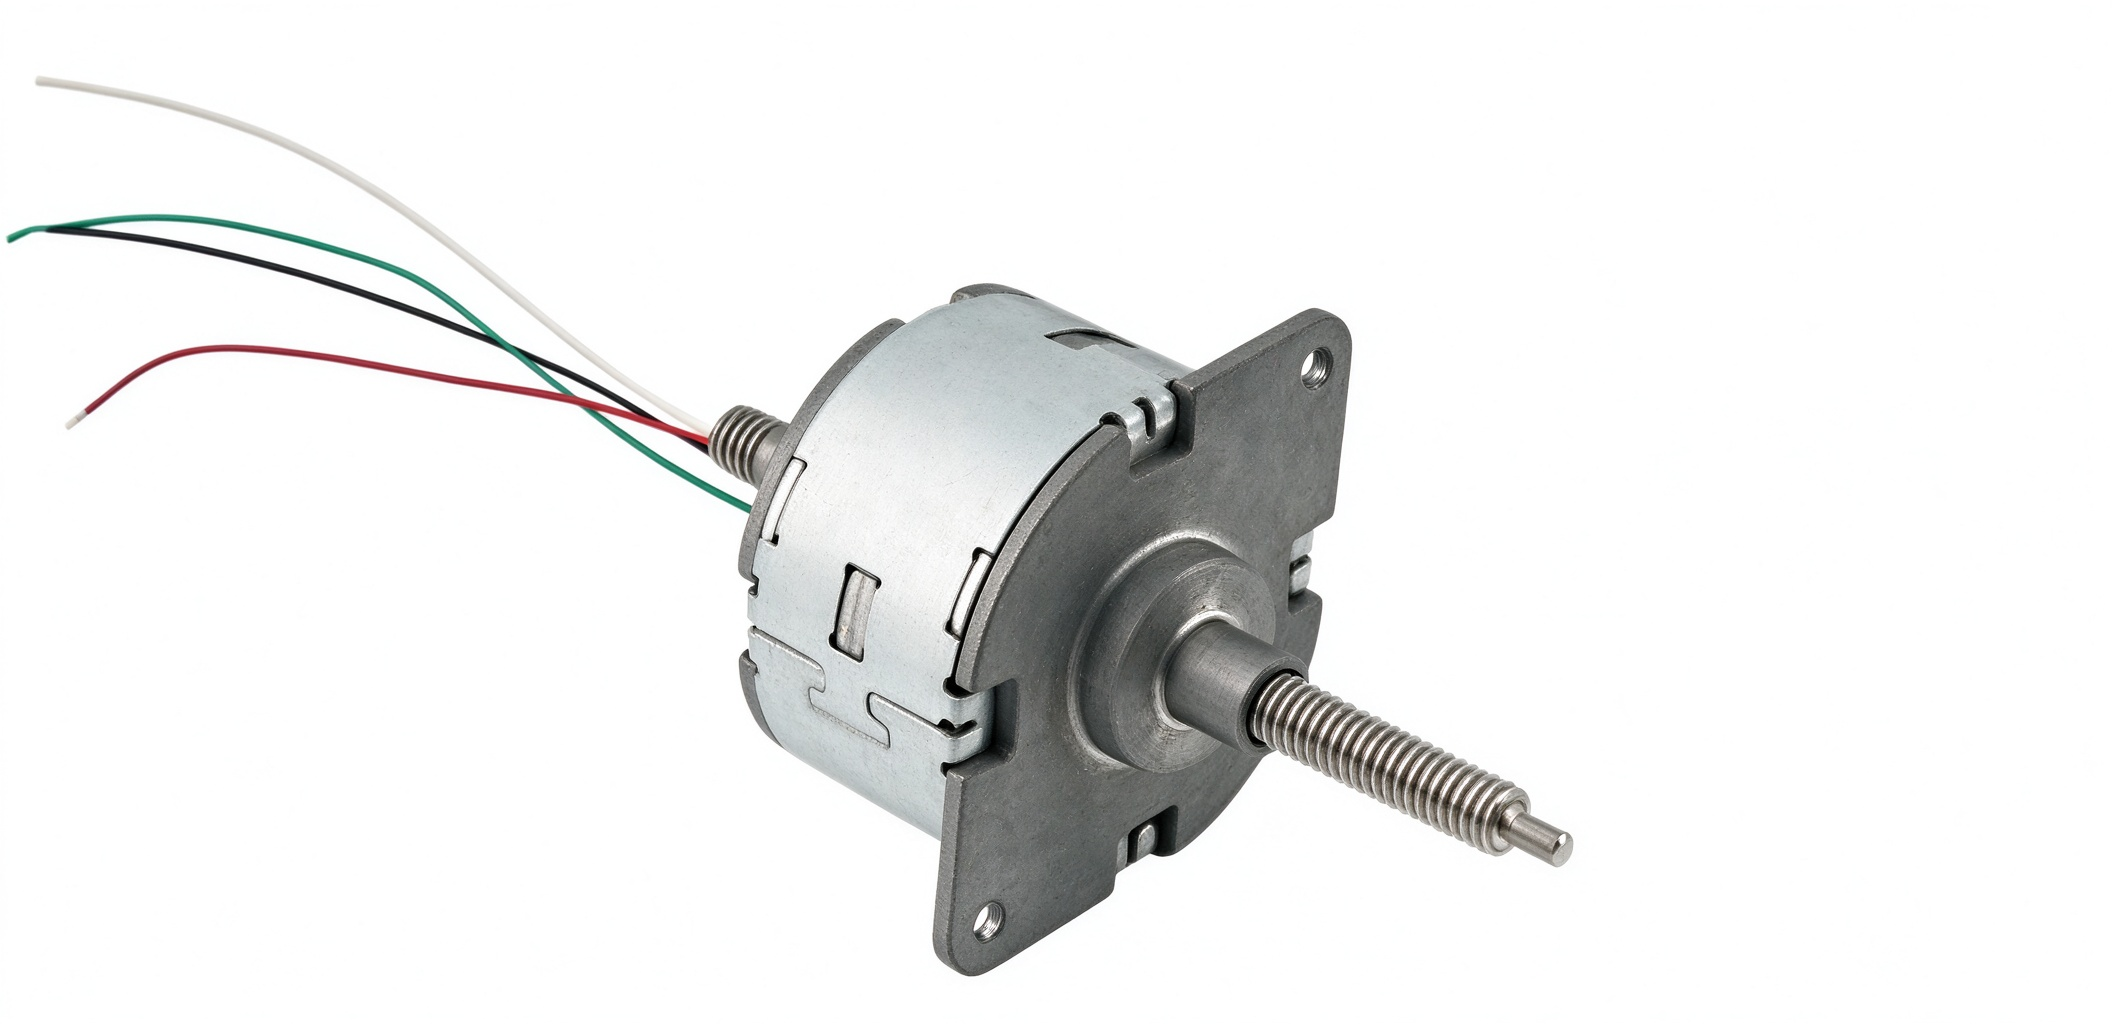
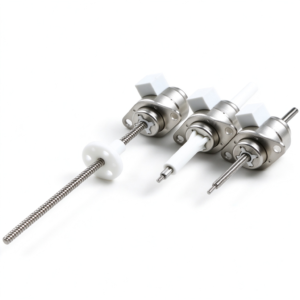
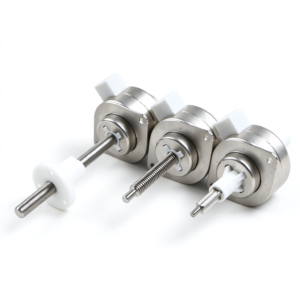
1. Fixed-axis type
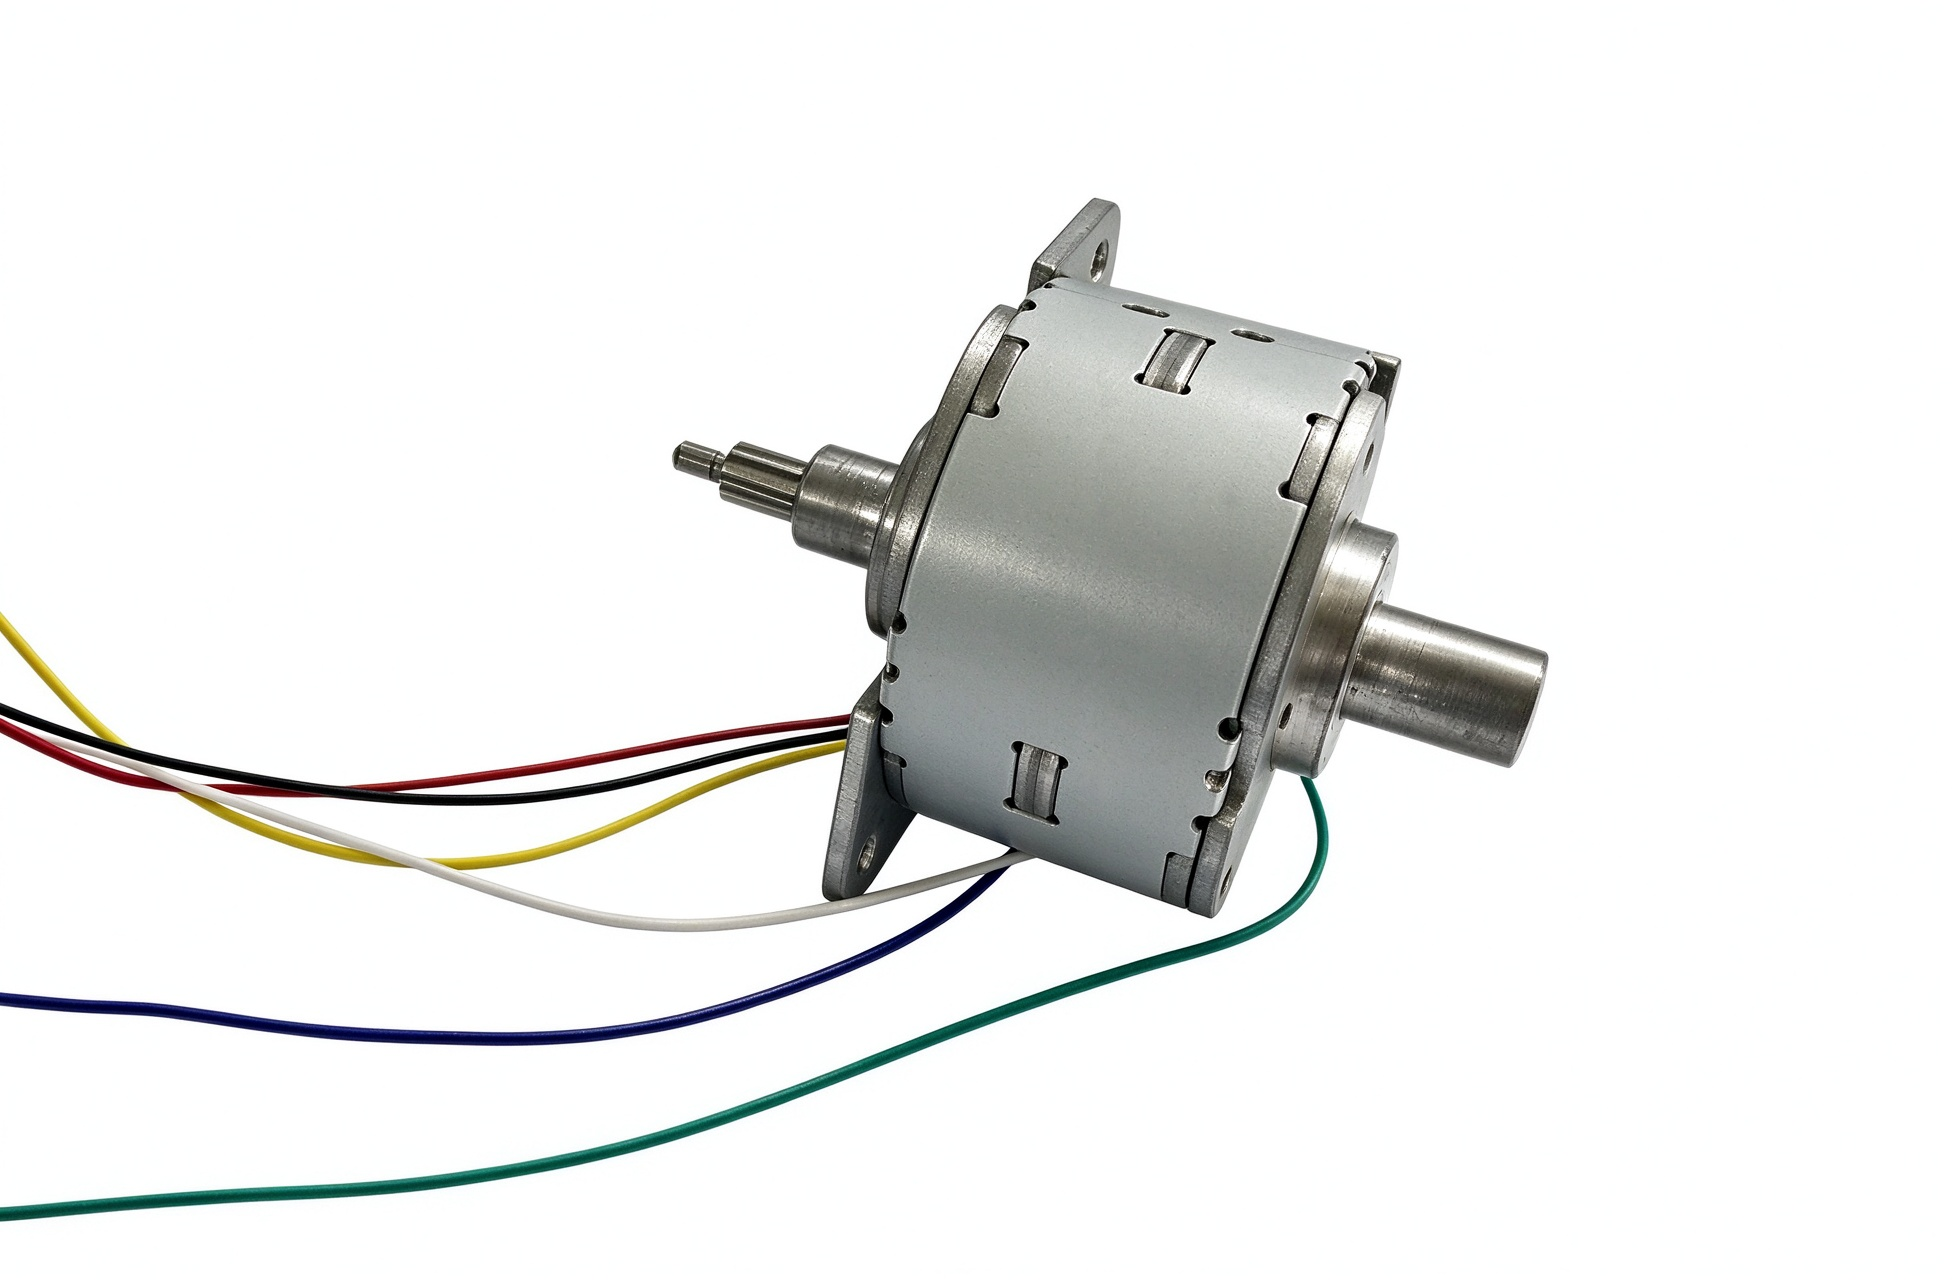
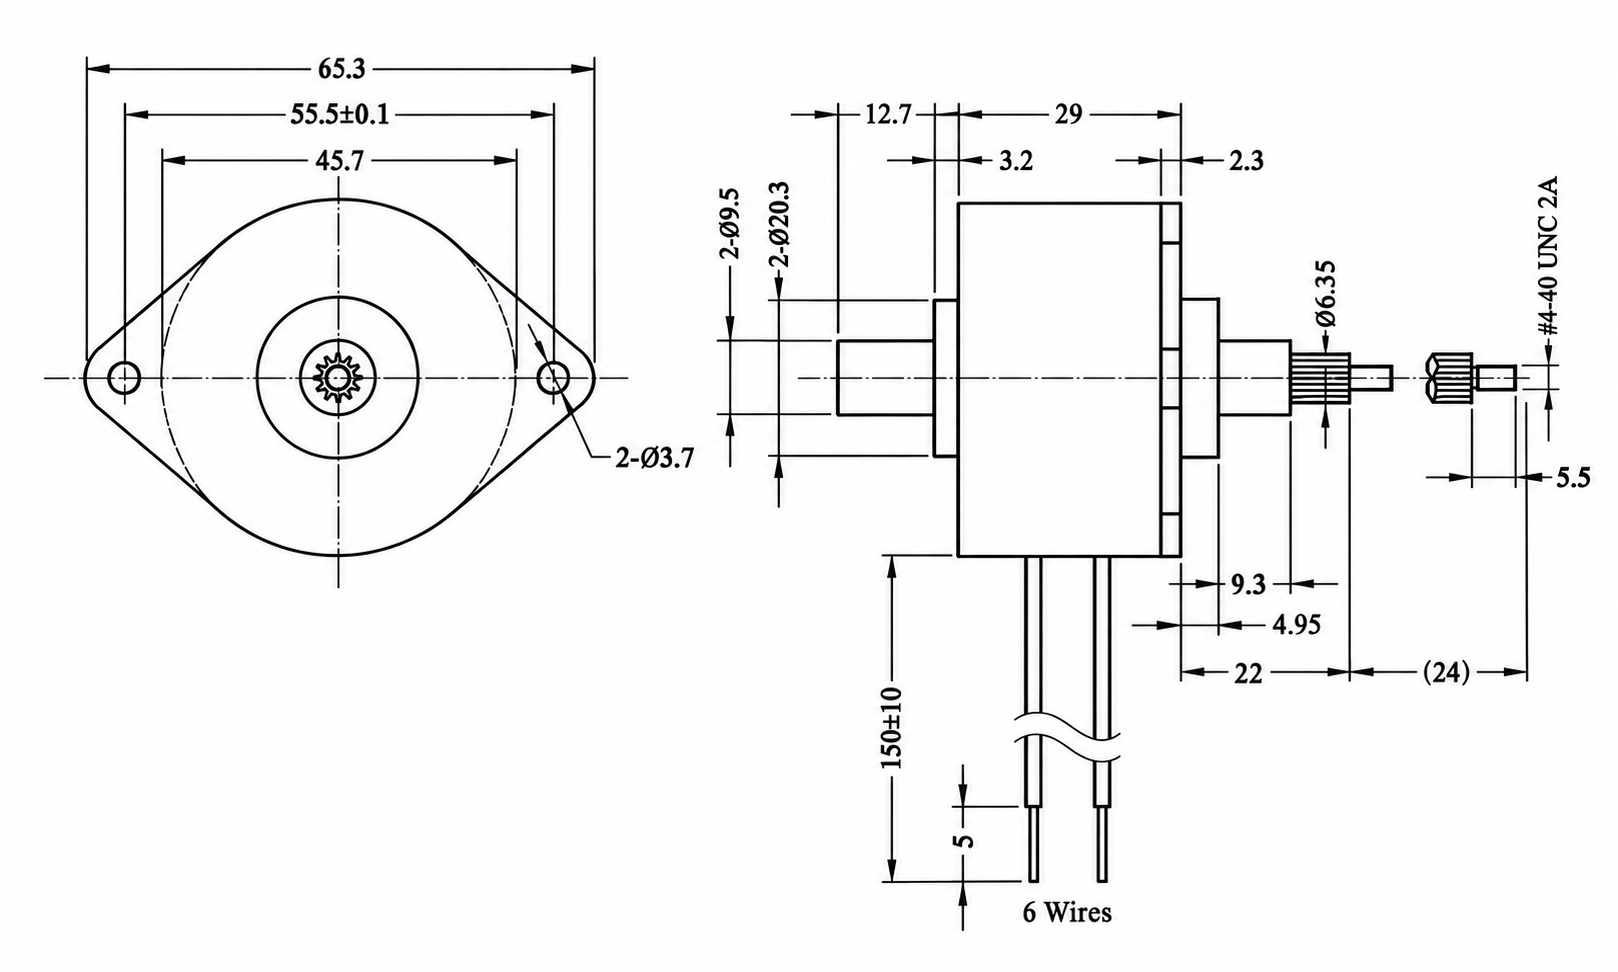
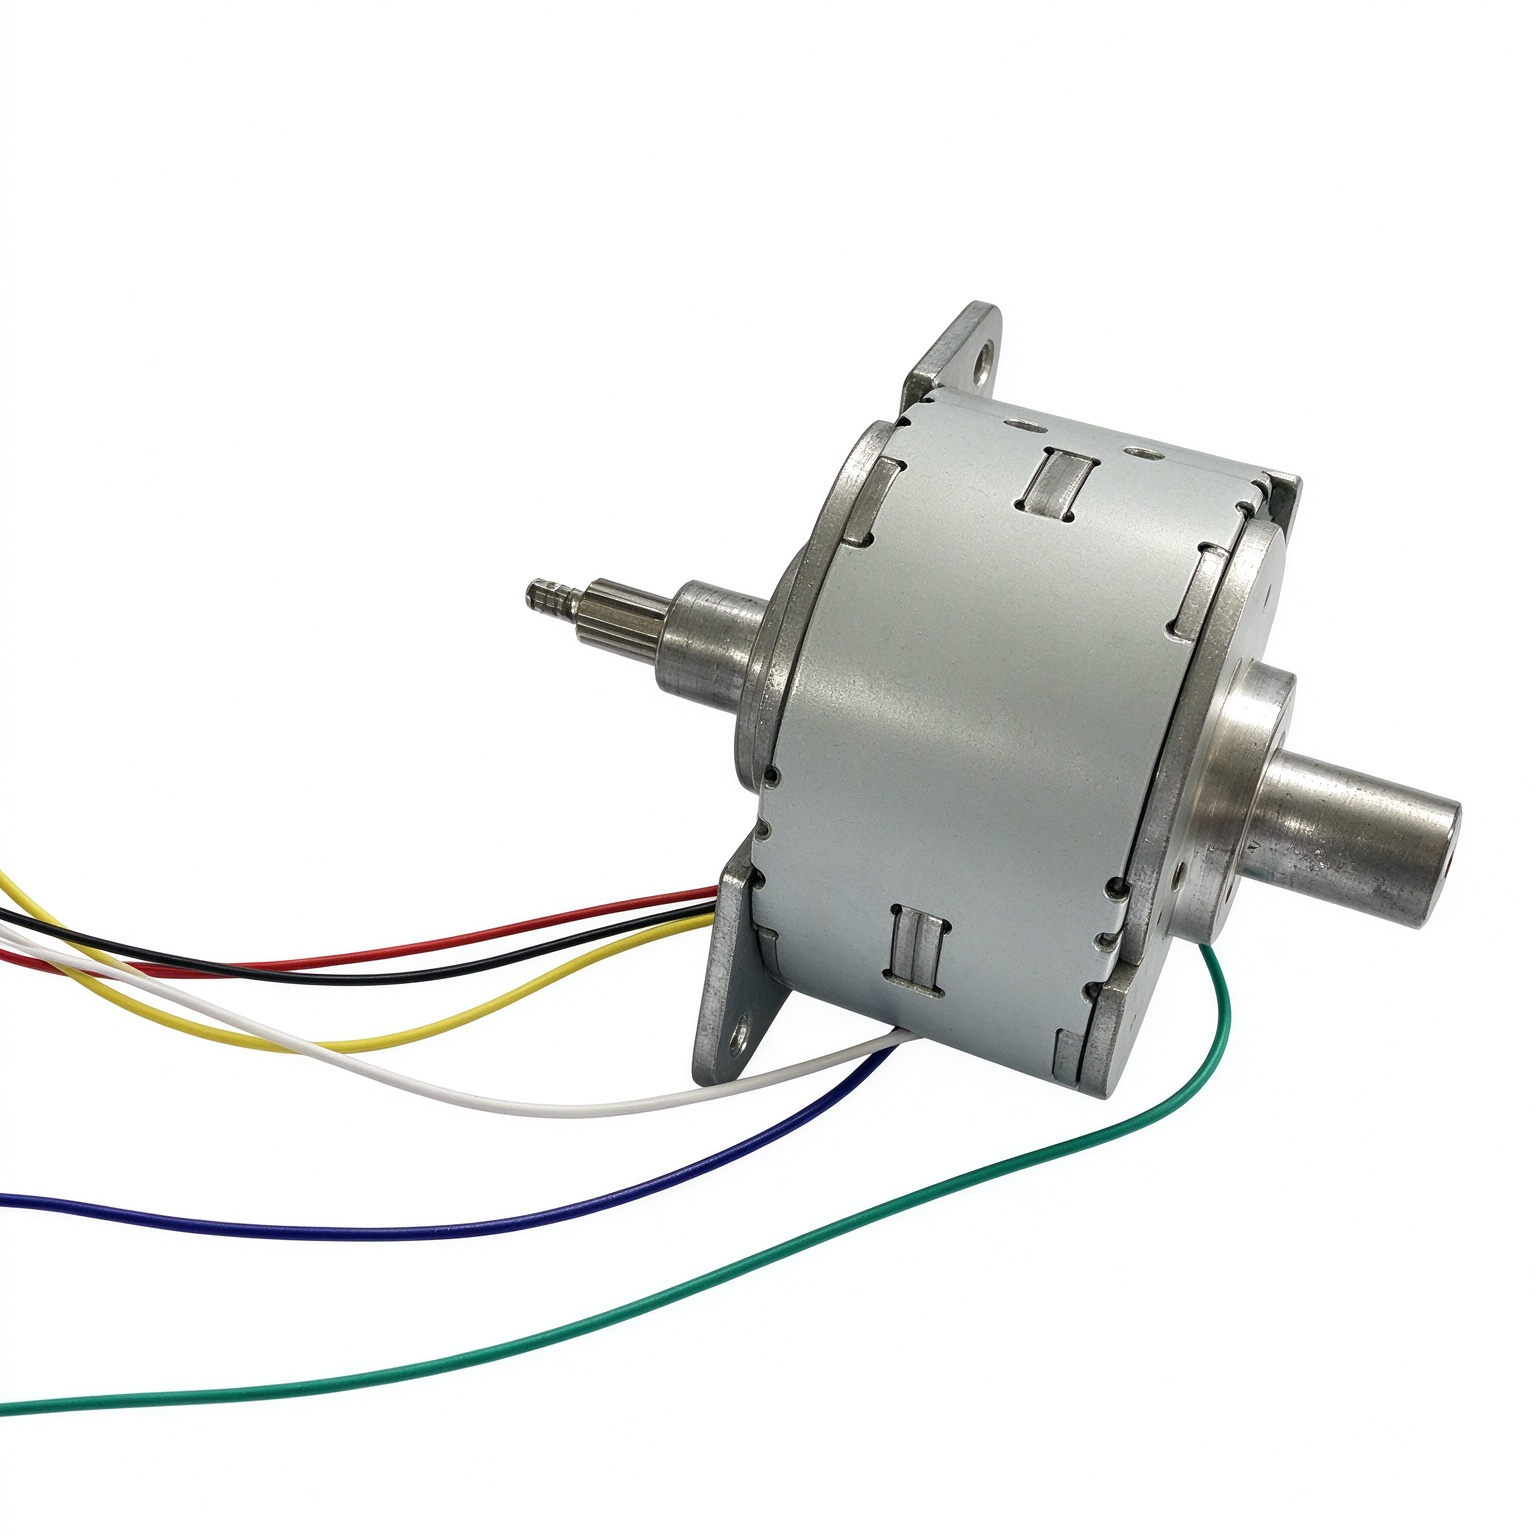
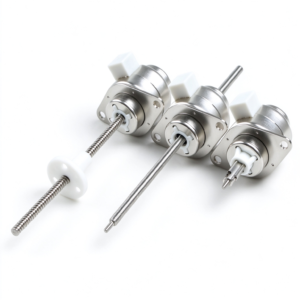
2. Through-shaft type
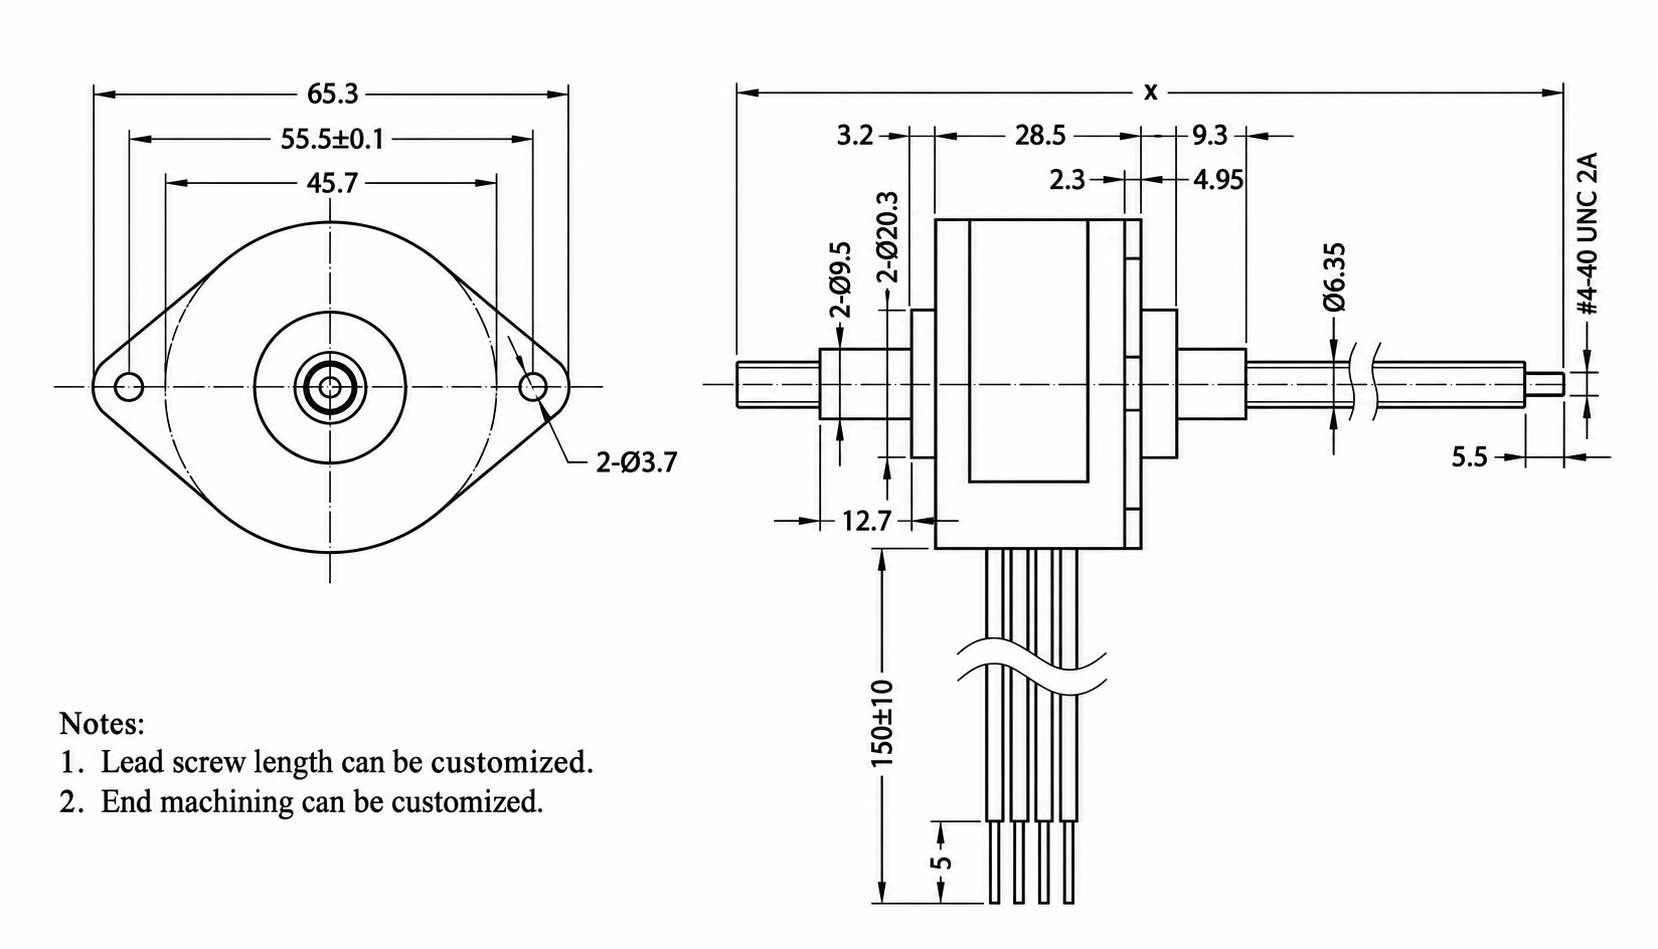
Step speed and thrust curve
Incremental Movement Control
Sequential winding excitation moves the motor through individual steps. The screw mechanism converts this motion into linear displacement, while a compatible driver and controller manage travel direction and movement commands.
Designers can use step-based control to create adjustment routines, staged movements, and automatic return sequences. The commanded travel depends on the step angle, screw lead, and selected drive mode.
Integrated Linear Transmission
Combining the motor and screw mechanism can simplify the arrangement of a linear motion assembly. This construction reduces the need to connect a separate rotary motor to an additional screw transmission.
The selected actuator configuration determines which component moves and how it connects to the load. Mounting points, shaft clearance, guidance, and anti-rotation arrangements should suit the chosen structure.
Controlled Extension and Retraction
Bidirectional operation supports forward and reverse travel within a programmed operating cycle. A compatible control system can coordinate movement distance, speed, direction changes, and pauses.
Suitable acceleration and deceleration settings help the motor move the load within its operating capability. These settings should account for friction, changing loads, and the available travel range.
Positioning System Integration
The Φ46 Series can form part of a positioning assembly that uses step commands to control displacement. A homing routine or reference switch can establish a known starting position before the mechanism begins its operating sequence.
Applications that require confirmation of actual position can incorporate suitable feedback. Overall positioning performance depends on mechanical backlash, alignment, loading, and drive settings.
Potential Applications
The series can be considered for mechanisms such as:
- Automated adjustment fixtures
- Guided linear positioning assemblies
- Instrument adjustment systems
- Optical positioning mechanisms
- Electrically operated opening and closing assemblies
- Equipment setup and calibration mechanisms
Suitability depends on the required thrust, travel speed, stroke, duty cycle, and installation conditions.
Mechanical Installation
Correct alignment helps the actuator transfer axial movement to the driven component. External guides should support the load where necessary and limit lateral forces or bending loads on the screw assembly.
Depending on the selected configuration, an external anti-rotation mechanism may be required. Appropriate travel limits and clearance help prevent damaging contact at the ends of movement.
Driver Compatibility and Operation
Use a stepper driver that matches the motor’s winding arrangement and electrical requirements. Current settings, excitation mode, and operating speed influence motor behavior and temperature.
Evaluate the motor, driver, controller, and mechanical assembly together under the intended working conditions. This helps establish suitable motion profiles and confirm that the selected actuator meets the equipment’s operating requirements.
Reviews
There are no reviews yet.